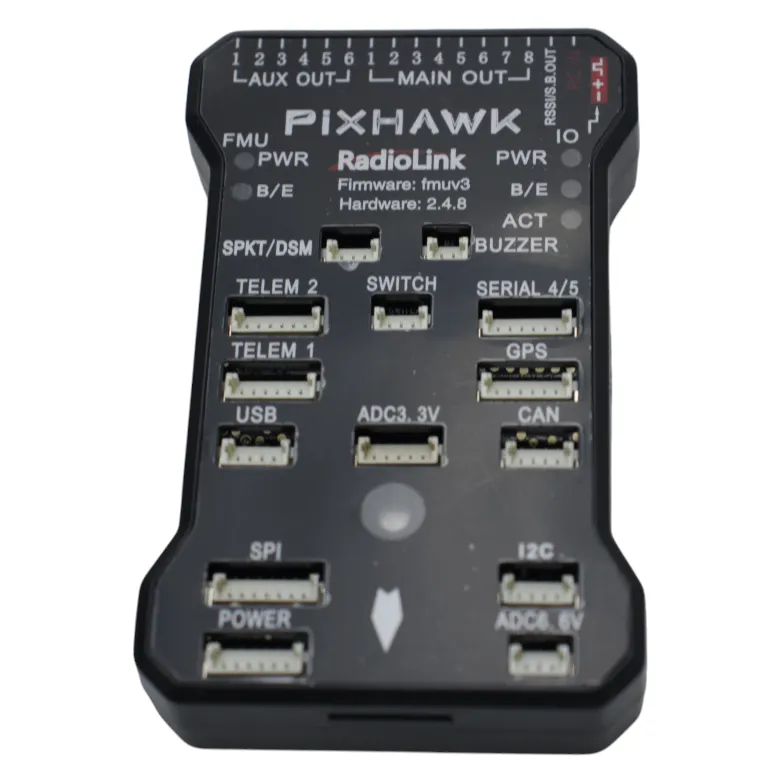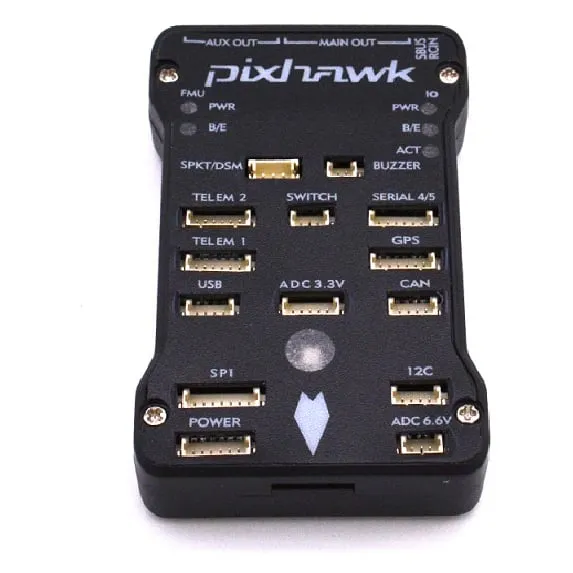
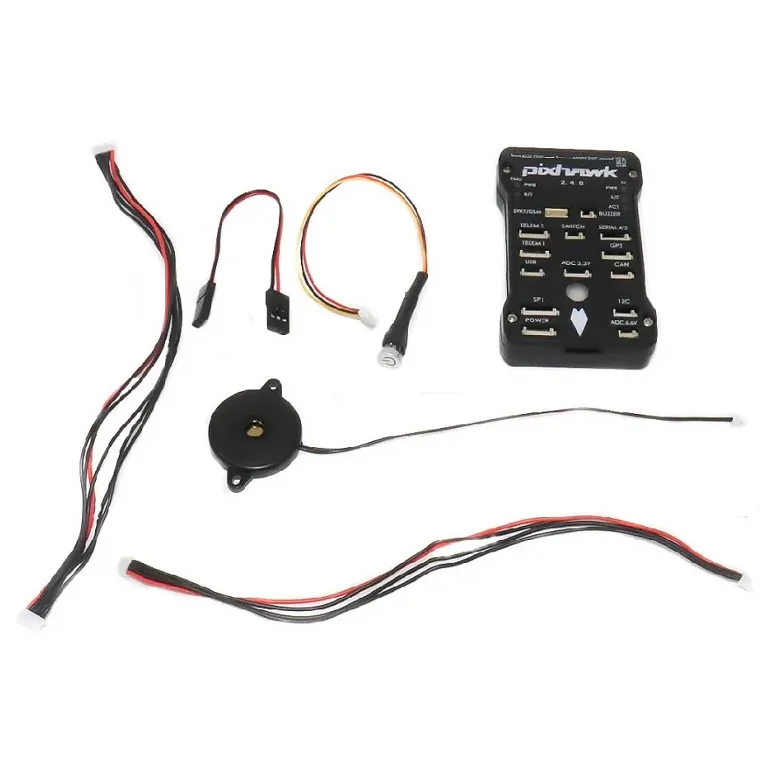
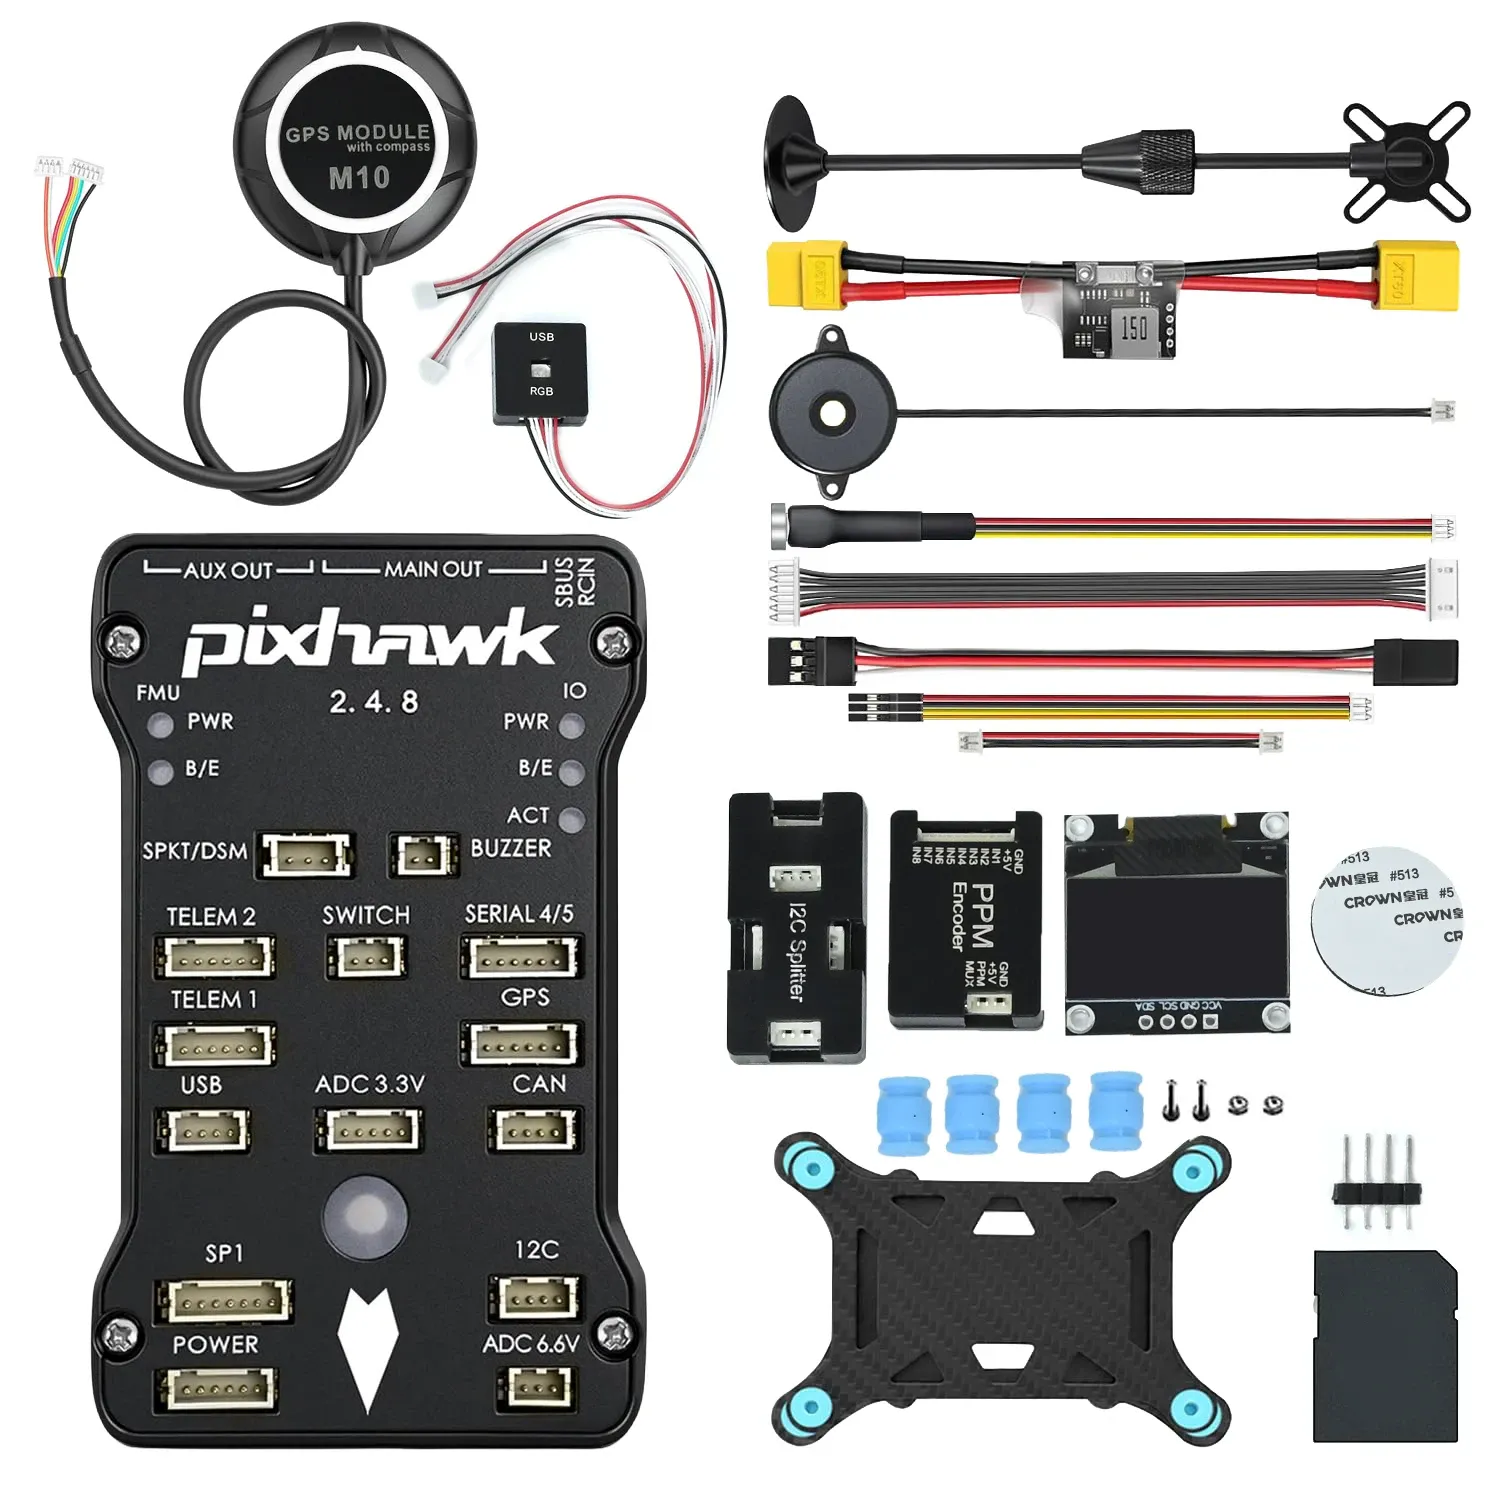
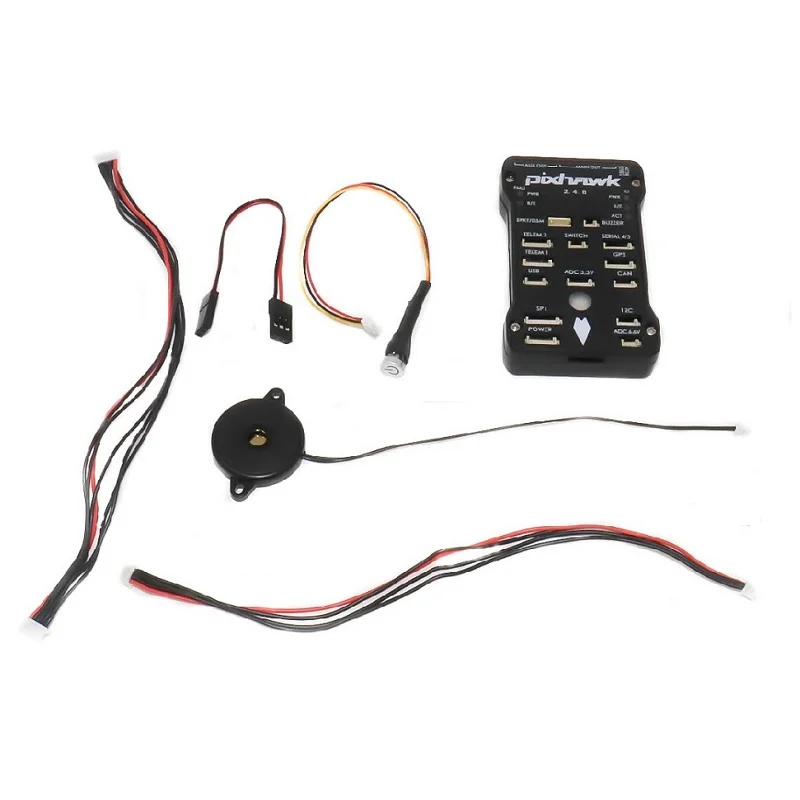
Pixhawk 2.4.8 PX4 32-Bit Autopilot Flight Controller
SKU PIXHAWK-248
Brand: Generic
Combo: Barebones
Free standard shipping on orders of ₹999 and above. Pan India delivery from Gurugram, Haryana.
Buying in bulk? Ask for a better price on WhatsApp or by email.
- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
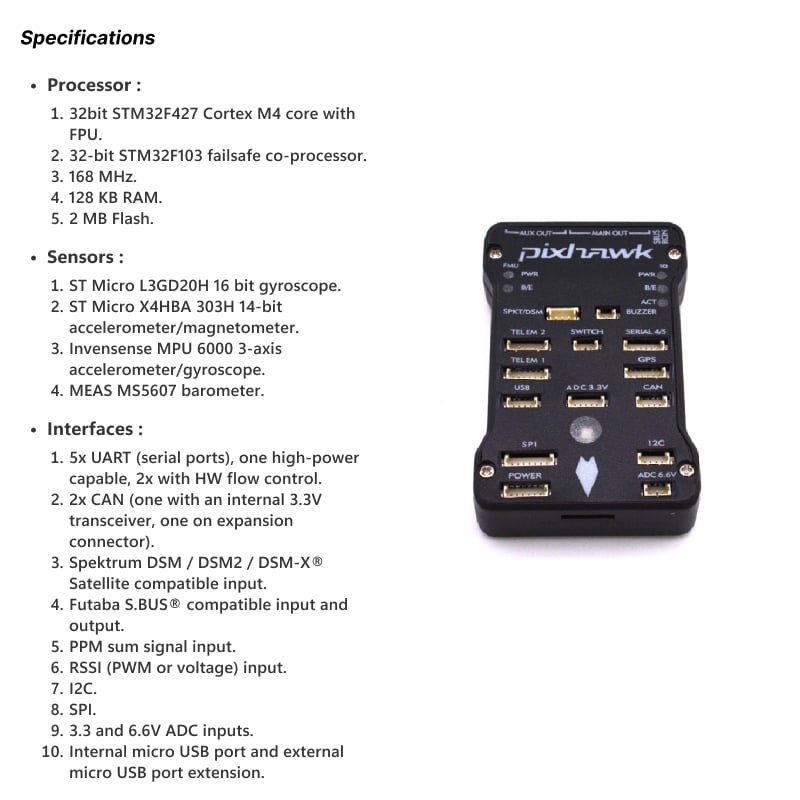
The Pixhawk 2.4.8 is a 32-bit autopilot flight controller built for autonomous multirotors, fixed-wing aircraft, VTOLs and ground rovers. A dual-processor design pairs an STM32F427 main MCU with an independent STM32F103 failsafe co-processor for backup control, and the board runs both ArduPilot (Copter, Plane, Rover) and PX4 firmware.
Key features
Dual-processor architecture: STM32F427 main MCU plus an STM32F103 failsafe co-processor.
Native support for ArduPilot and PX4, covering autonomous multirotor, fixed-wing and rover platforms.
Onboard InvenSense MPU6000 gyro/accelerometer and an MS5607 barometer for stable altitude hold.
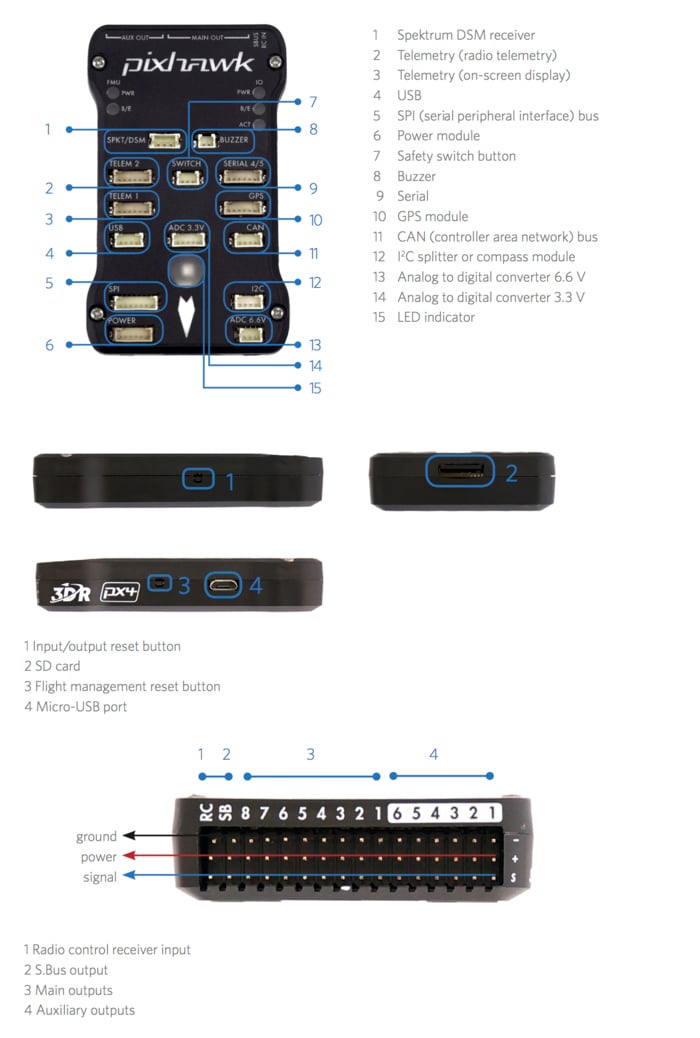
5x UART, 2x CAN bus, I2C, SPI and dedicated ADC inputs for GPS, telemetry, airspeed and power-module wiring.
Built-in microSD card slot for Blackbox-style logging and post-flight mission analysis.
Accepts PPM, Futaba S.BUS and Spektrum DSM/DSM2/DSM-X receiver inputs.
Specifications
Main processor: STM32F427 (32-bit ARM Cortex-M4 with FPU, 168 MHz)
Failsafe co-processor: STM32F103
Memory: 2 MB flash
Gyro/accelerometer: InvenSense MPU6000
Additional sensors: L3GD20H gyroscope, LSM303D accelerometer/magnetometer (onboard compass)
Barometer: MS5607
Supported firmware: ArduPilot, PX4
Serial ports: 5x UART
PWM/servo outputs: 14
USB: micro USB (internal port plus external extension)
Power the board through a regulated 5V power module wired to the PM port for accurate battery telemetry, and mount it on vibration-damping foam away from motors and power wiring for reliable altitude and position hold.
| Integrated Receiver | No |
|---|---|
| Integrated VTX | No |
| FC Processor | F4 |
| Gyro | MPU6000 |
| Brand | Generic, ReadyToSky |
| Supported Firmware | PX4, ArduPilot |
| Barometer | Yes |
| UARTs | 5 |
| Compass Included | Yes |
| Motor Outputs | 14 |
From builders
Reviews
No reviews yet — be the first to write one.
Compatible
Complete your build
Related