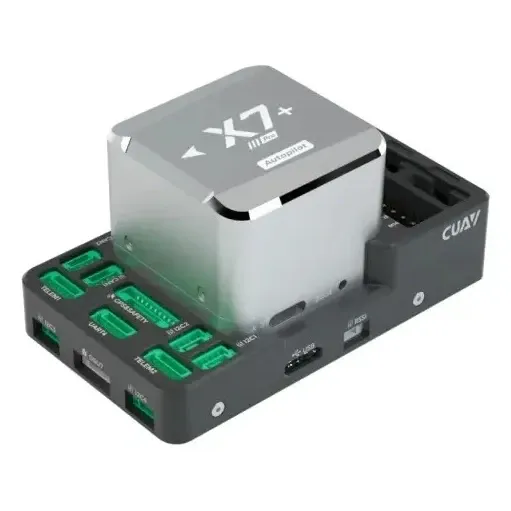
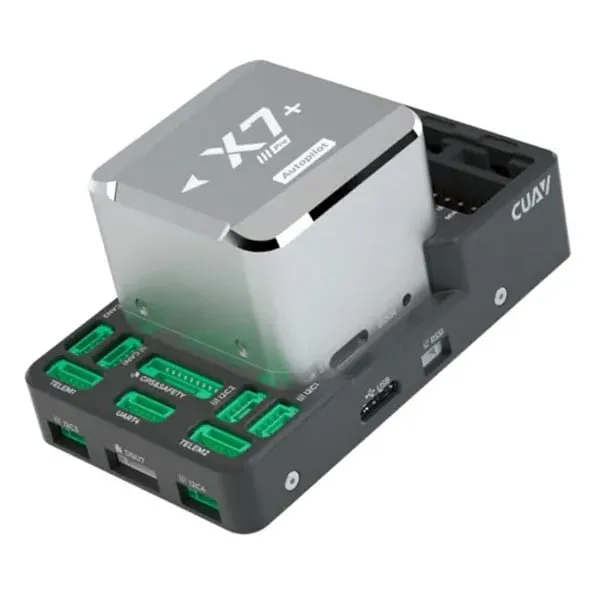
CUAV X7+ Pro Flight Controller for PX4 and ArduPilot
SKU CUAV-X7-PLUS-PRO
Free shipping. Pan India delivery from Gurugram, Haryana.
Ships within 3–4 business days — quality-checked in Gurugram before dispatch
Questions about this part? Ask us on WhatsApp- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
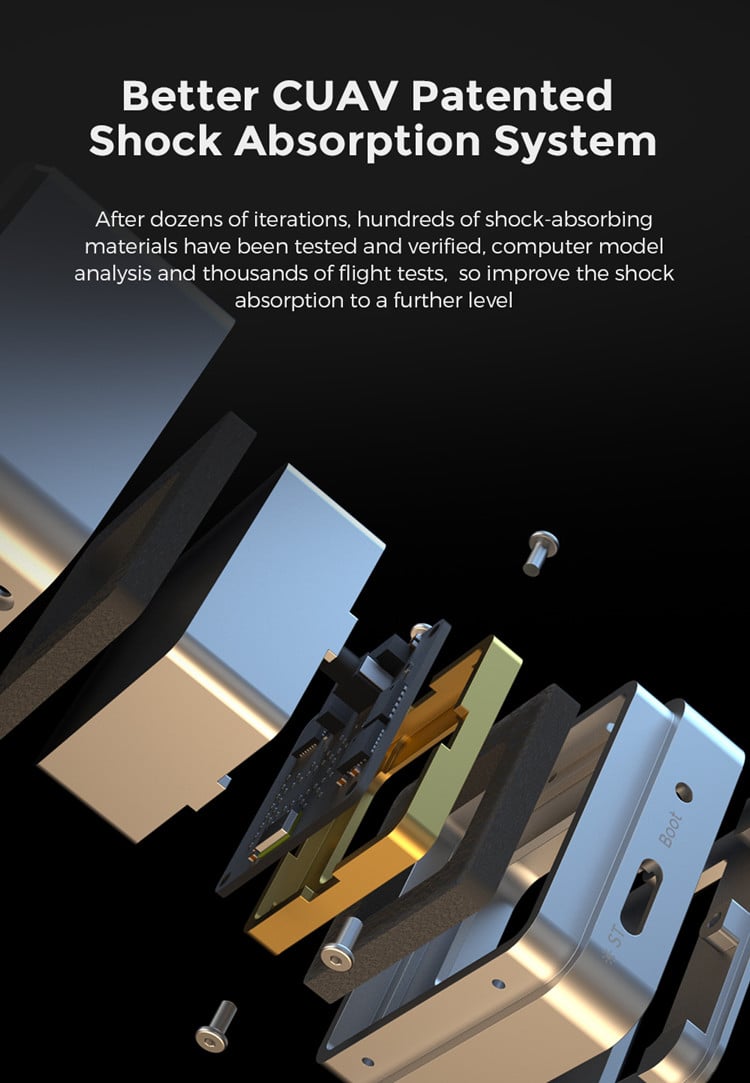
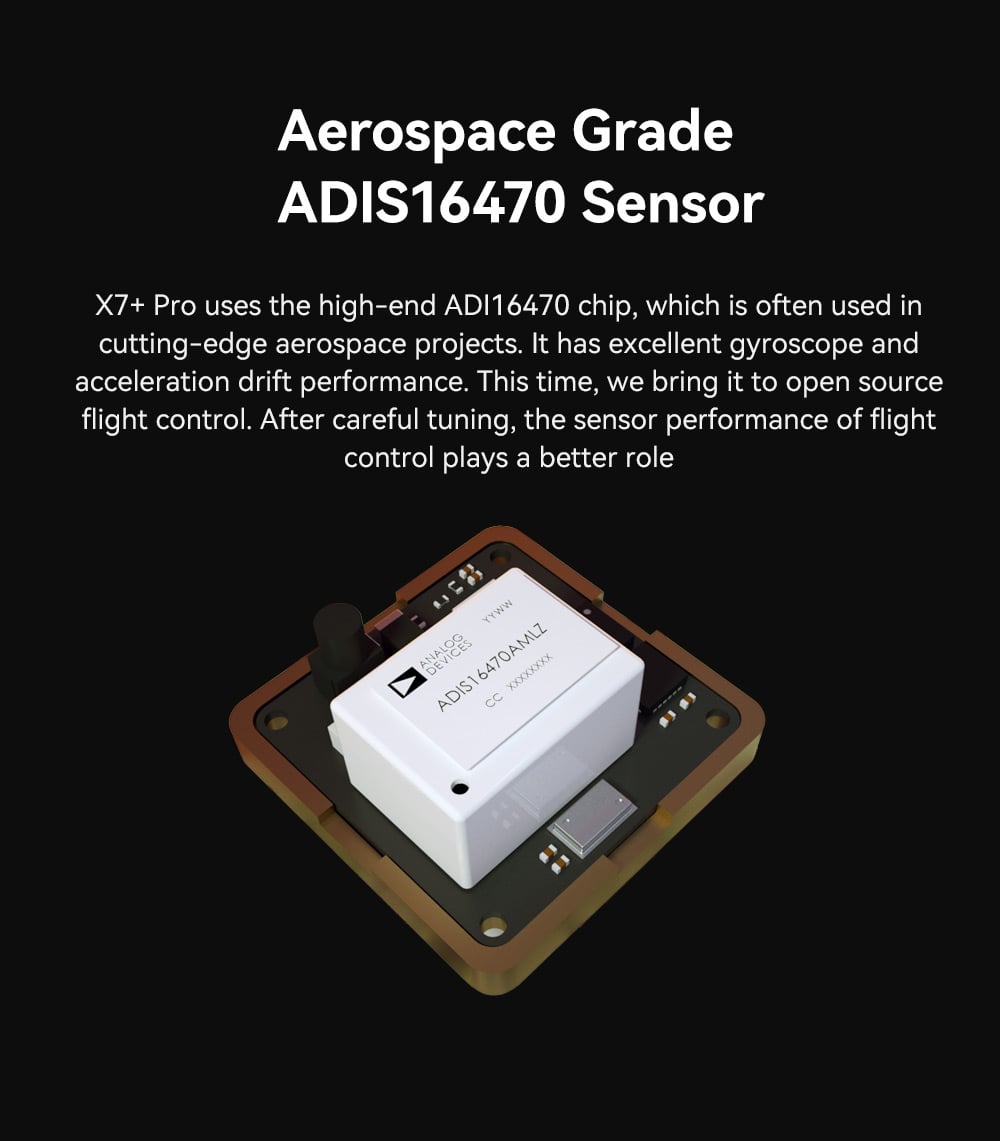
The CUAV X7+ Pro is an industrial-grade autopilot for ArduPilot and PX4, aimed at survey, mapping and commercial multirotors, fixed-wing and VTOL aircraft where sensor redundancy matters. It pairs an STM32H743 processor with an aerospace-grade ADIS16470 IMU, CUAV's built-in shock isolation and sensor temperature compensation.
Key features
Three redundant IMU sets with automatic failover, led by the ADIS16470; IMU heating keeps readings stable in cold conditions
Dual MS5611 barometers and an industrial RM3100 compass on board
14 PWM outputs, 12 of them bidirectional-DShot capable (M1–M12)
Two GPS ports, two CAN buses, a dedicated UAVCAN battery port and support for CAN power monitors
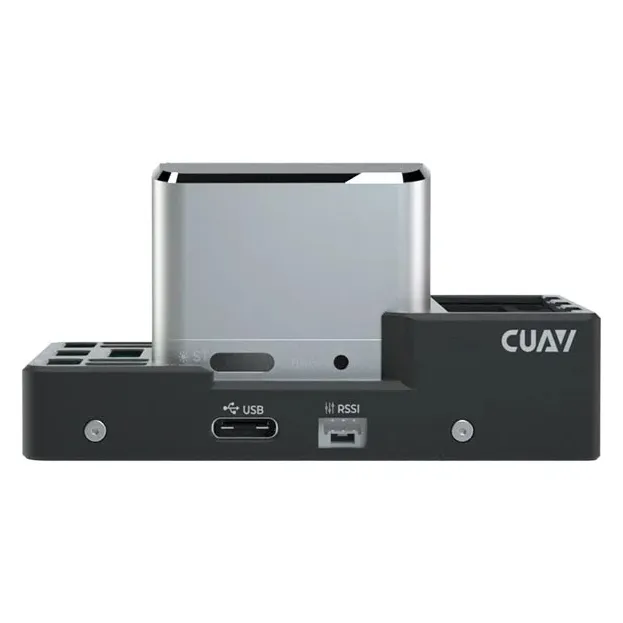
High-speed USB-C for faster log downloads; the modular core also suits custom carrier boards
Specifications
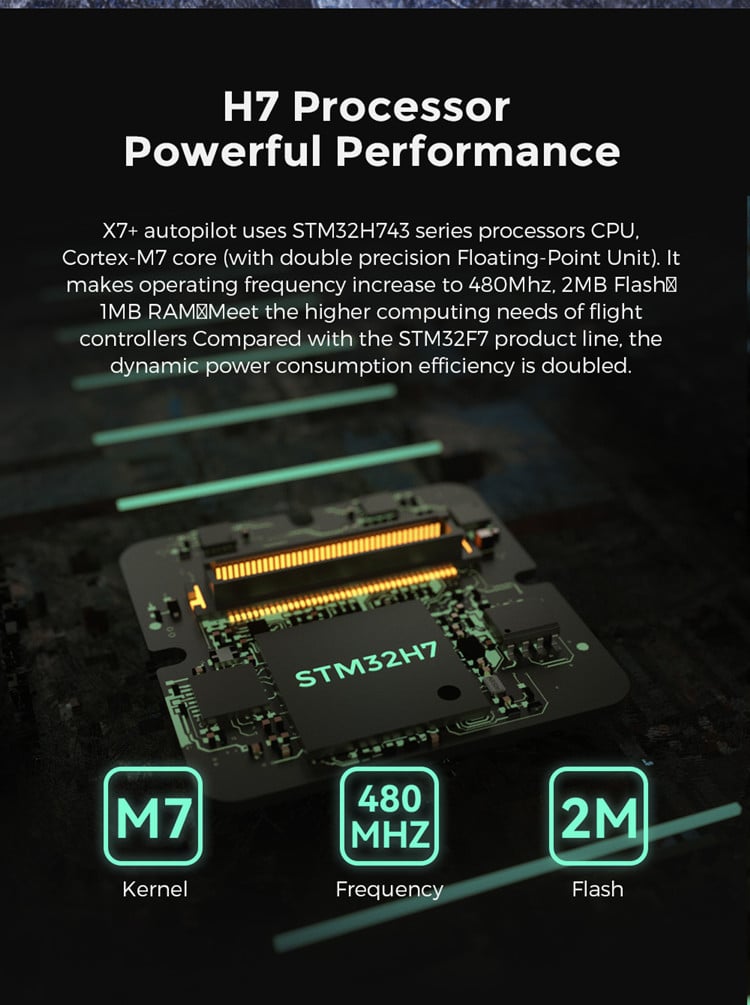
Processor: STM32H743, 480 MHz, 1 MB RAM, 2 MB flash
IMUs: triple redundant, including ADIS16470 and ICM-20649
Barometers: 2 × MS5611
Compass: RM3100
PWM outputs: 14 (12 with DShot)
RC input: SBUS / CPPM / DSM
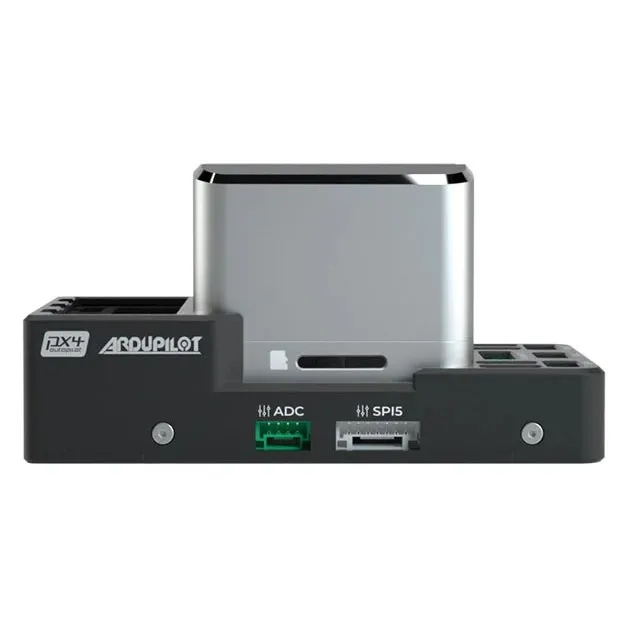
Interfaces: 2 × GPS, 2 × CAN, 2 × power, 2 × ADC, USB-C
Power input: 4.5–5.4 V
Operating temperature: −20 °C to 80 °C
Weight: 105 g
Firmware: ArduPilot 4.1 or later, PX4 1.12.3 or later
Feed both power ports from separate power modules to make use of the redundant supply, and add an external GPS on GPS1 for navigation.
| FC Processor | H743 |
|---|---|
| Gyro | ADIS16470, ICM20649 |
| Made in India | No |
| Brand | CUAV |
| Supported Firmware | ArduPilot, PX4 |
| Barometer | Yes |
| Weight | 105 g |
| Compass Included | Yes |
| RC Protocol | SBUS |
From builders
Reviews
No reviews yet — be the first to write one.
Compatible
Complete your build
Related