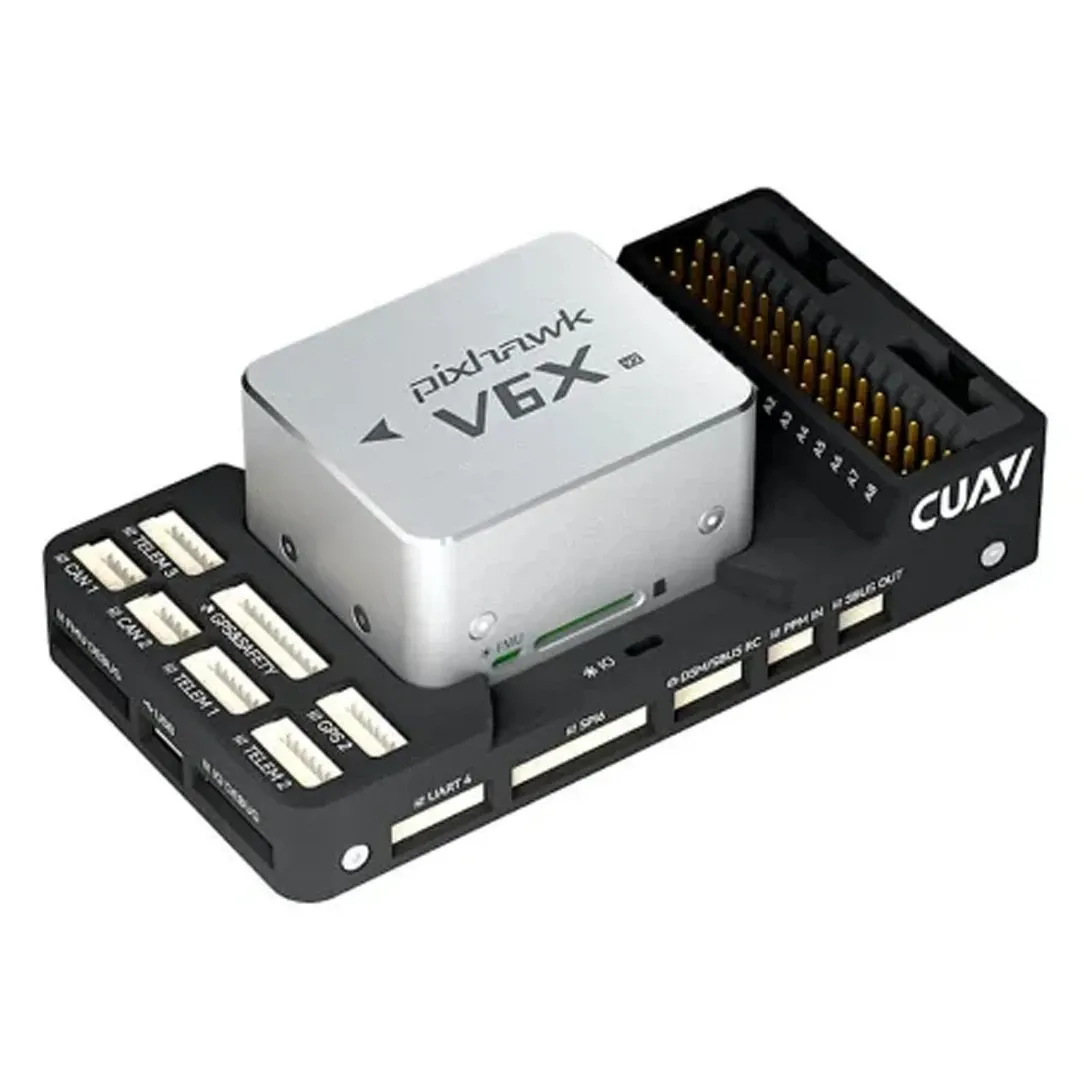
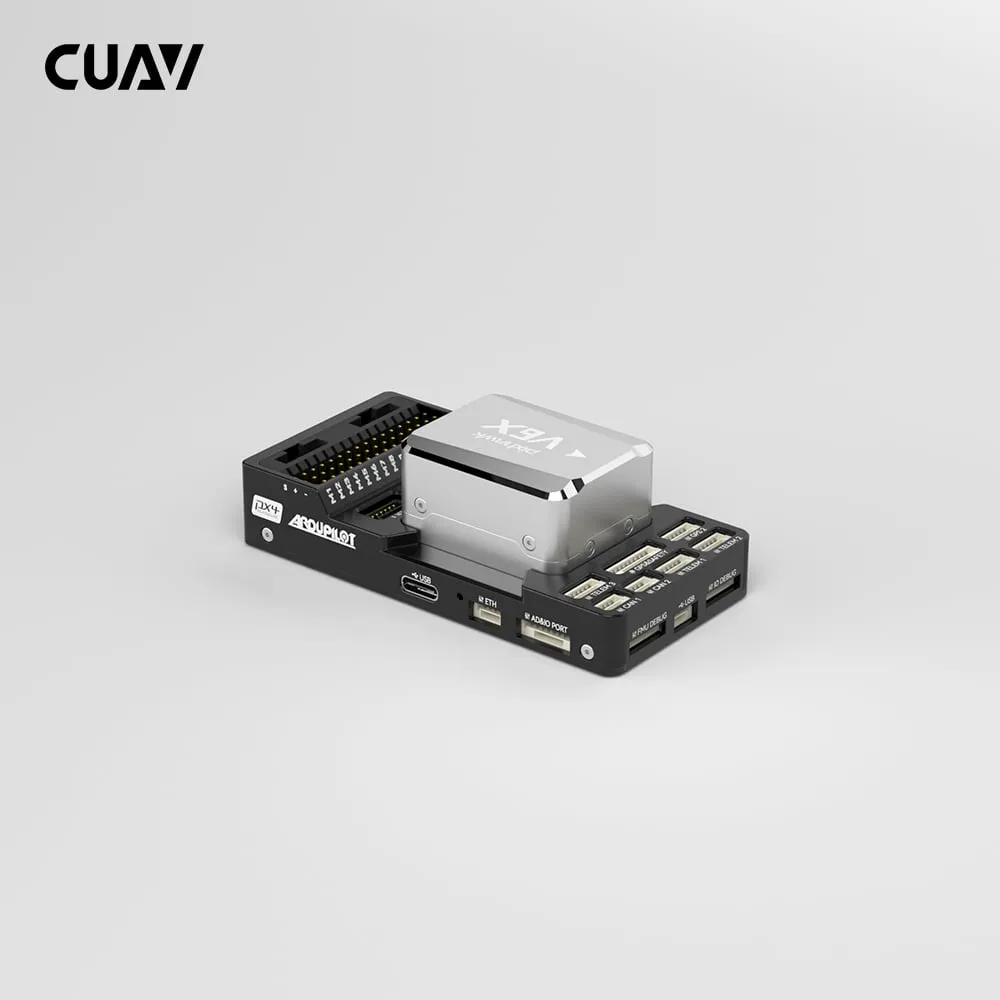
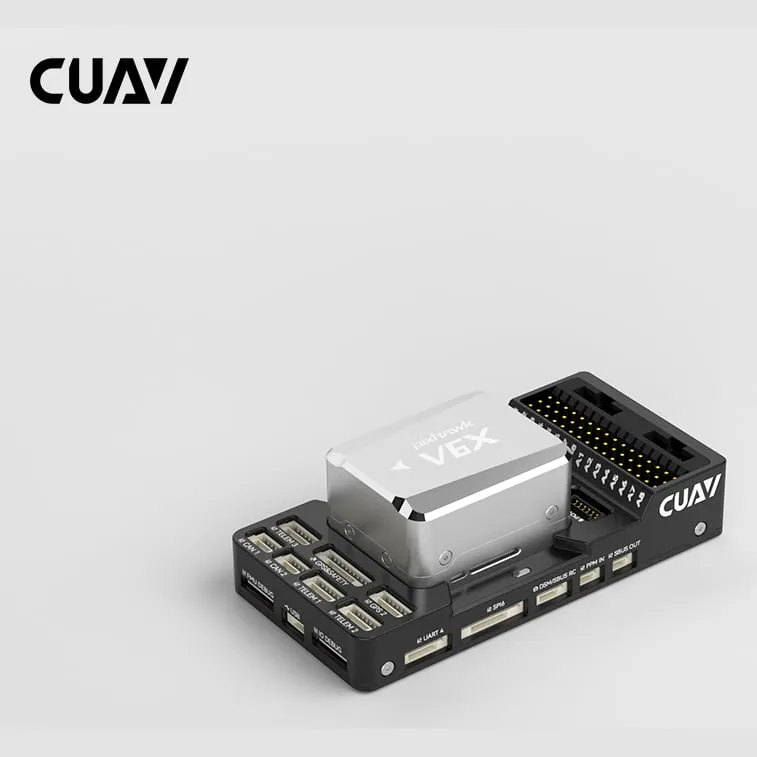
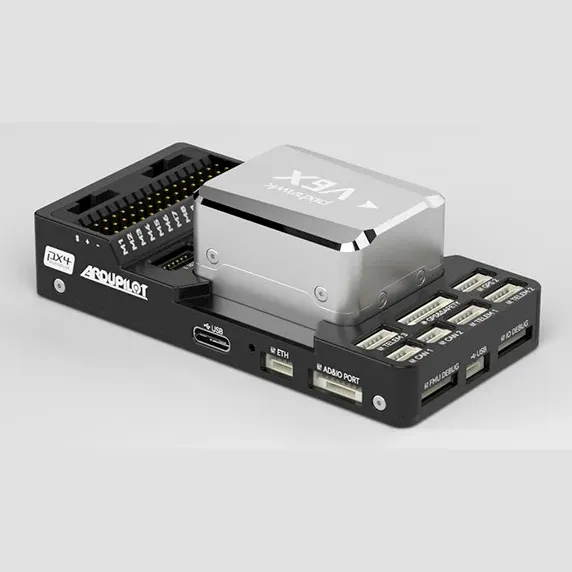
CUAV Pixhawk V6X Flight Controller
SKU CUAV-PIXHAWK-V6X
Free standard shipping on orders of ₹999 and above. Pan India delivery from Gurugram, Haryana.
Buying in bulk? Ask for a better price on WhatsApp or by email.
- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
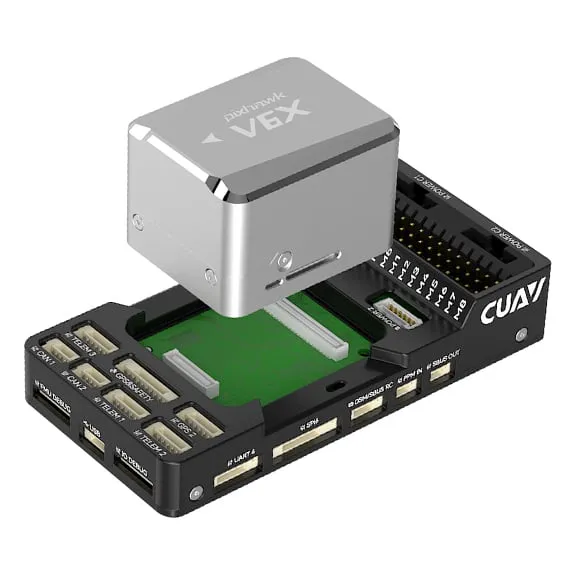
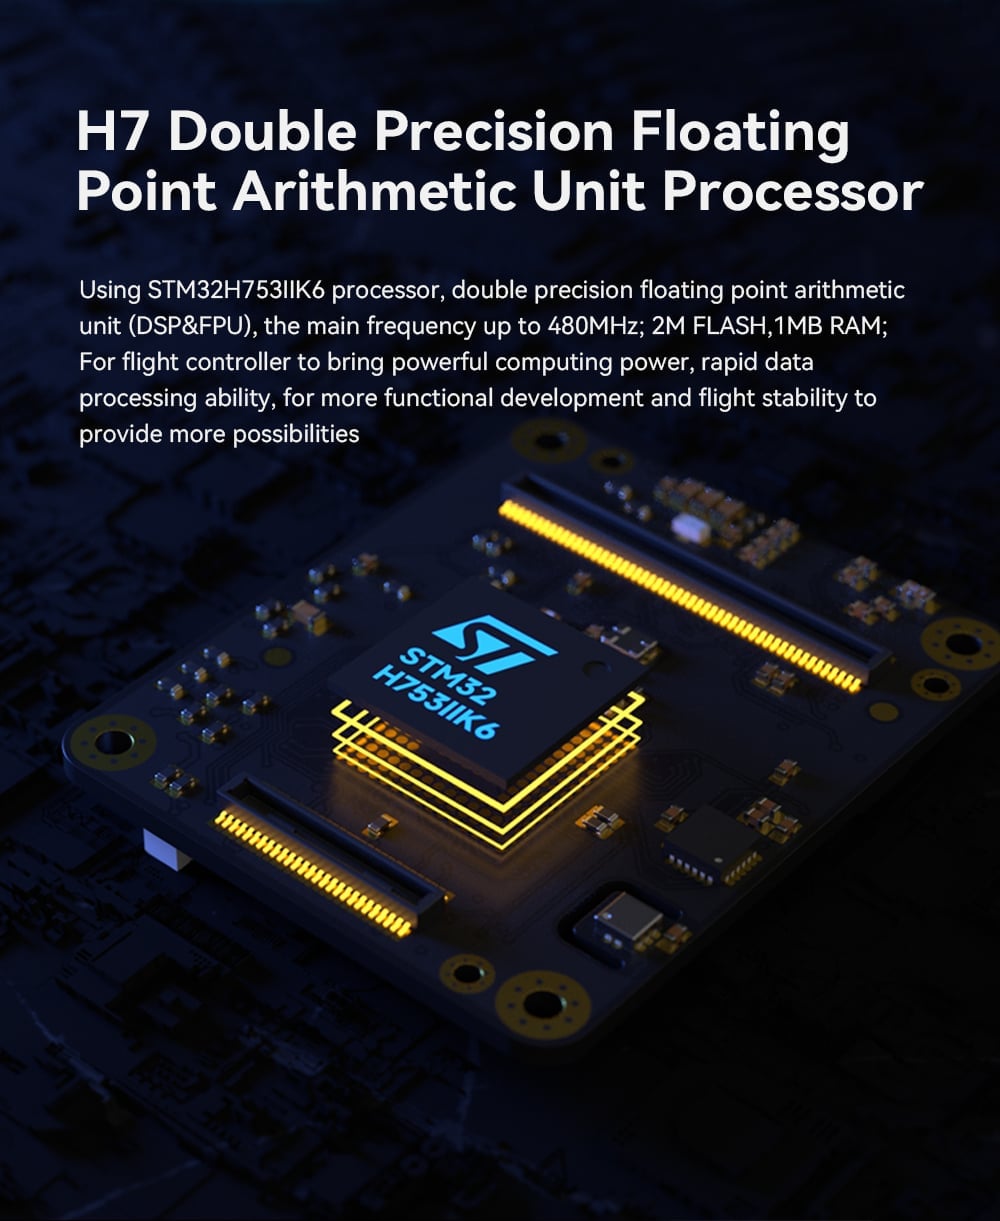
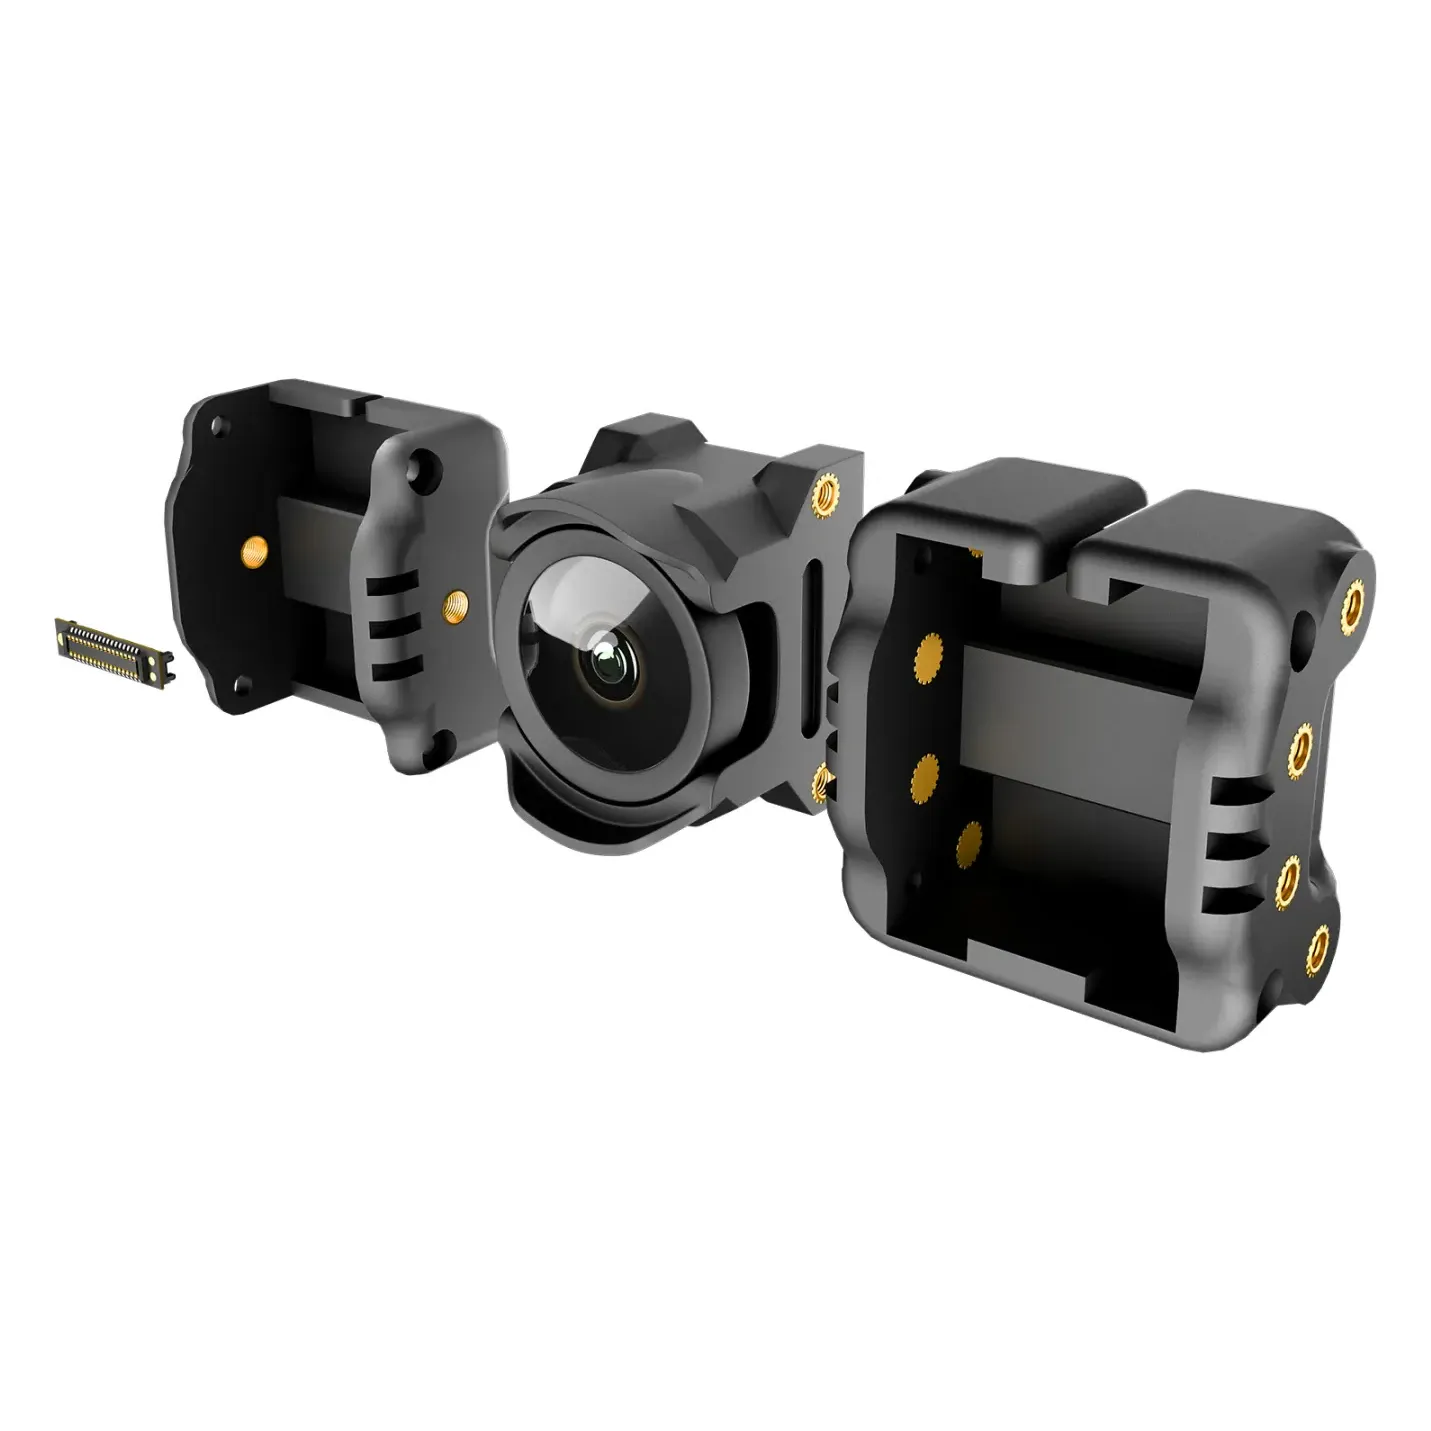
The CUAV Pixhawk V6X is an autopilot built to the Pixhawk FMUv6X open standard. It is designed for industrial multirotors, VTOLs and survey aircraft running PX4 or ArduPilot. The H7 main processor and the Cortex-M3 I/O coprocessor run on independent buses and power supplies, and both the IMUs and the barometers are redundant.
Key features
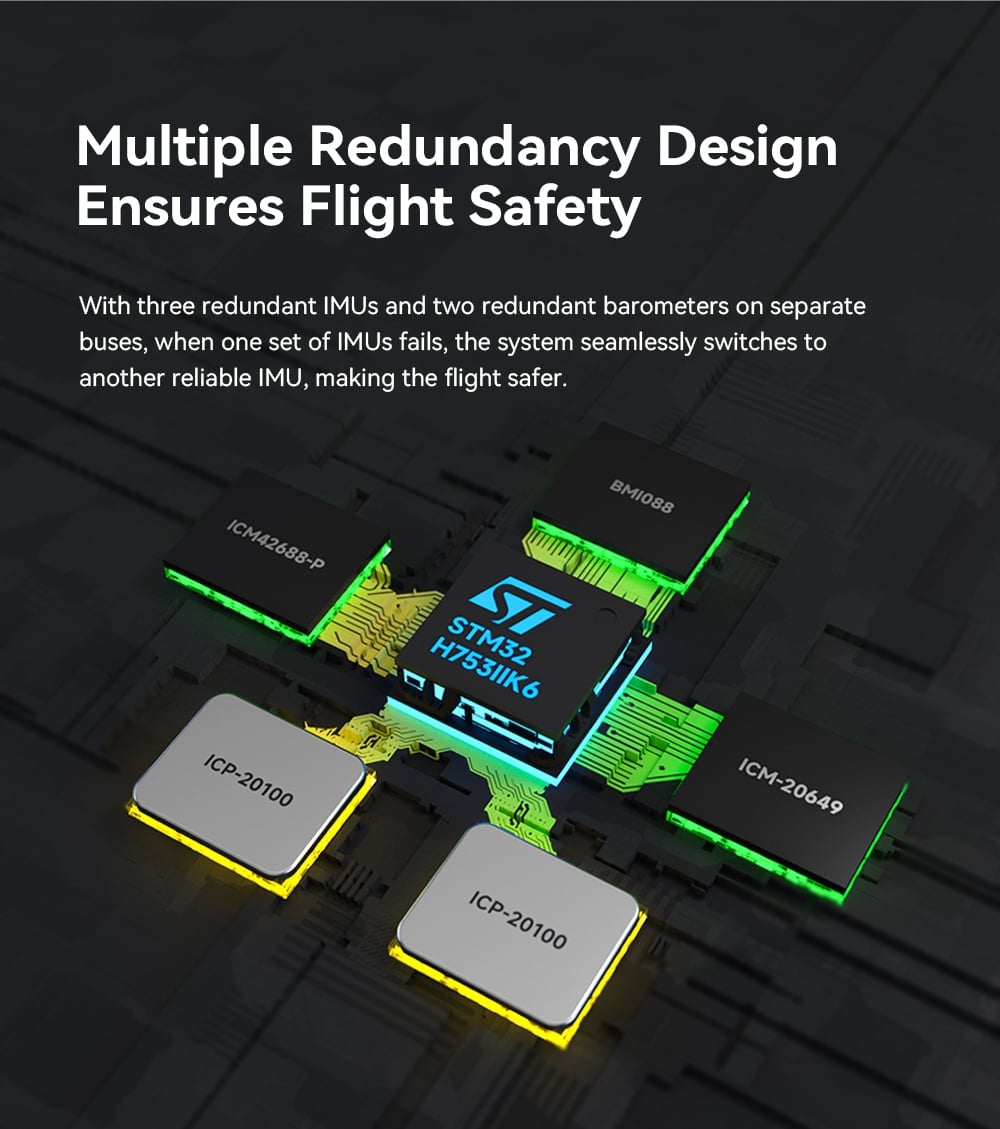
Triple redundant IMUs: BMI088, ICM-42688-P and ICM-20649, heated and temperature-calibrated at the factory. If one fails, the system switches to another.
Dual barometers and RM3100 compass: two ICP-20100 sensors on separate buses, plus an automotive-grade RM3100 magnetometer.
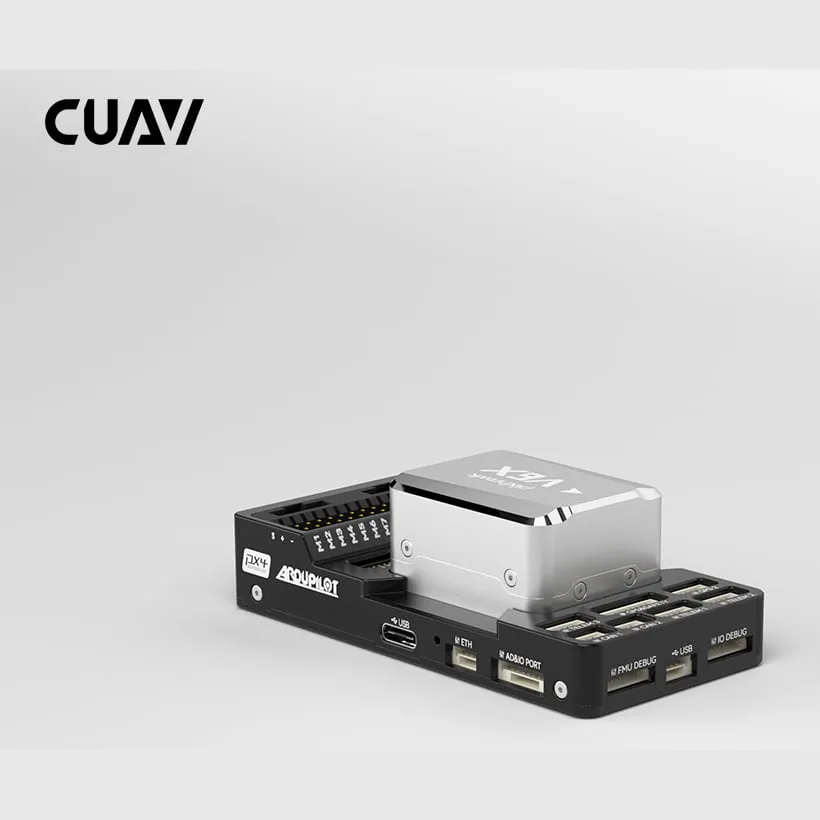
100 Mbps Ethernet: a high-speed link to a companion computer, inertial navigation unit or mapping camera.
16 PWM outputs and two CAN buses: enough for octocopters, VTOL control surfaces and DroneCAN peripherals.
Built-in shock absorption: IMU damping is integrated into the module.
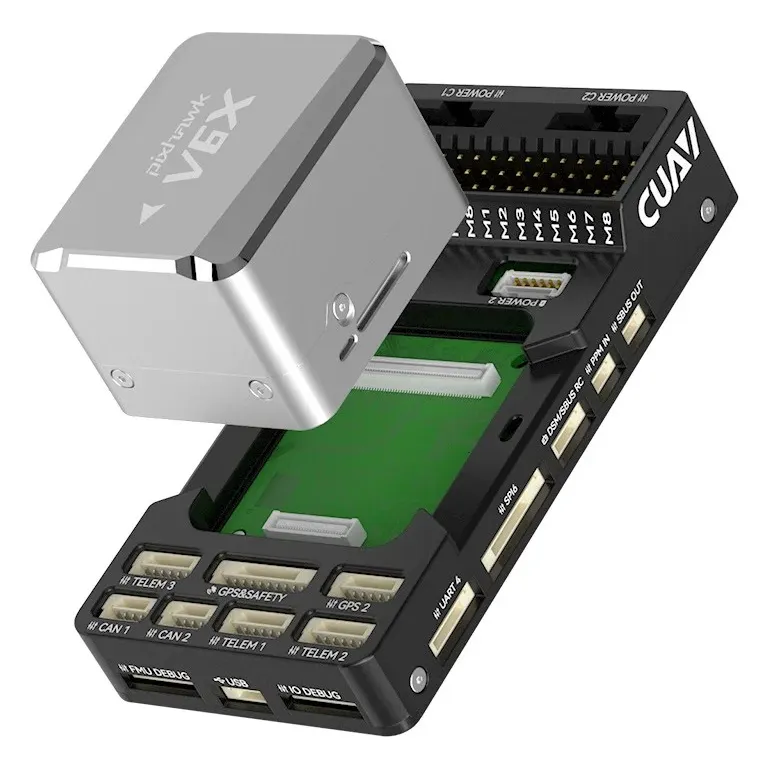
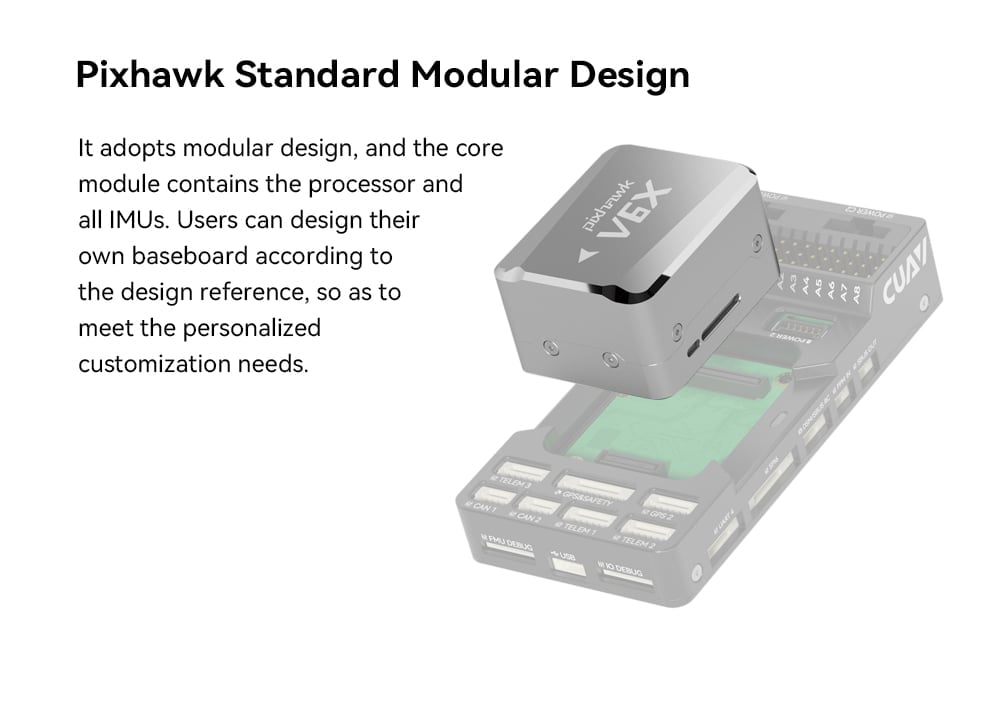
Modular design: the core and baseboard join through Pixhawk Autopilot Bus connectors.
Specifications
Main processor: STM32H753, Cortex-M7, 480 MHz, 2 MB flash, 1 MB RAM
I/O processor: STM32F103, Cortex-M3, 72 MHz
IMUs: BMI088, ICM-42688-P, ICM-20649
Barometers: 2x ICP-20100
Magnetometer: RM3100
PWM outputs: 16
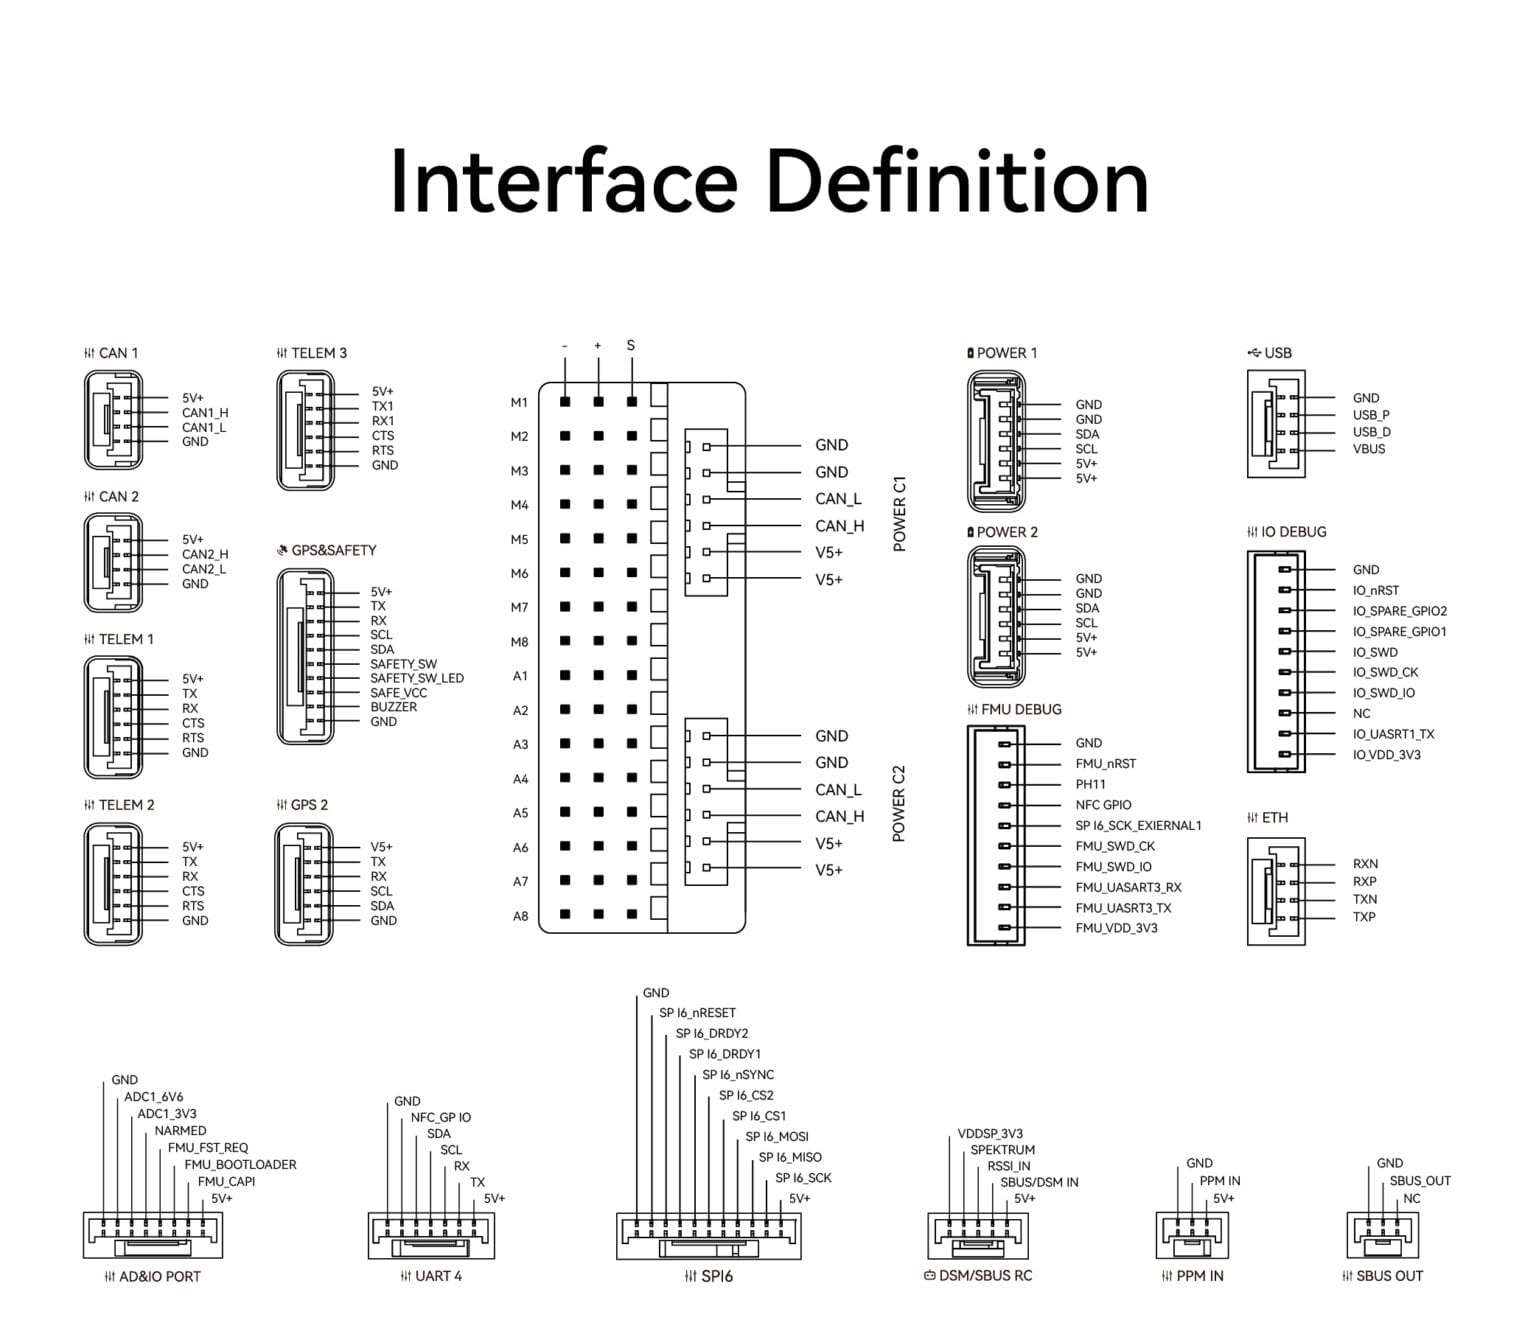
Serial ports: 3 TELEM with flow control, GPS1, GPS2, UART4
CAN buses: 2
Ethernet: 1 x 100 Mbps
RC input: Spektrum/DSM, S.Bus
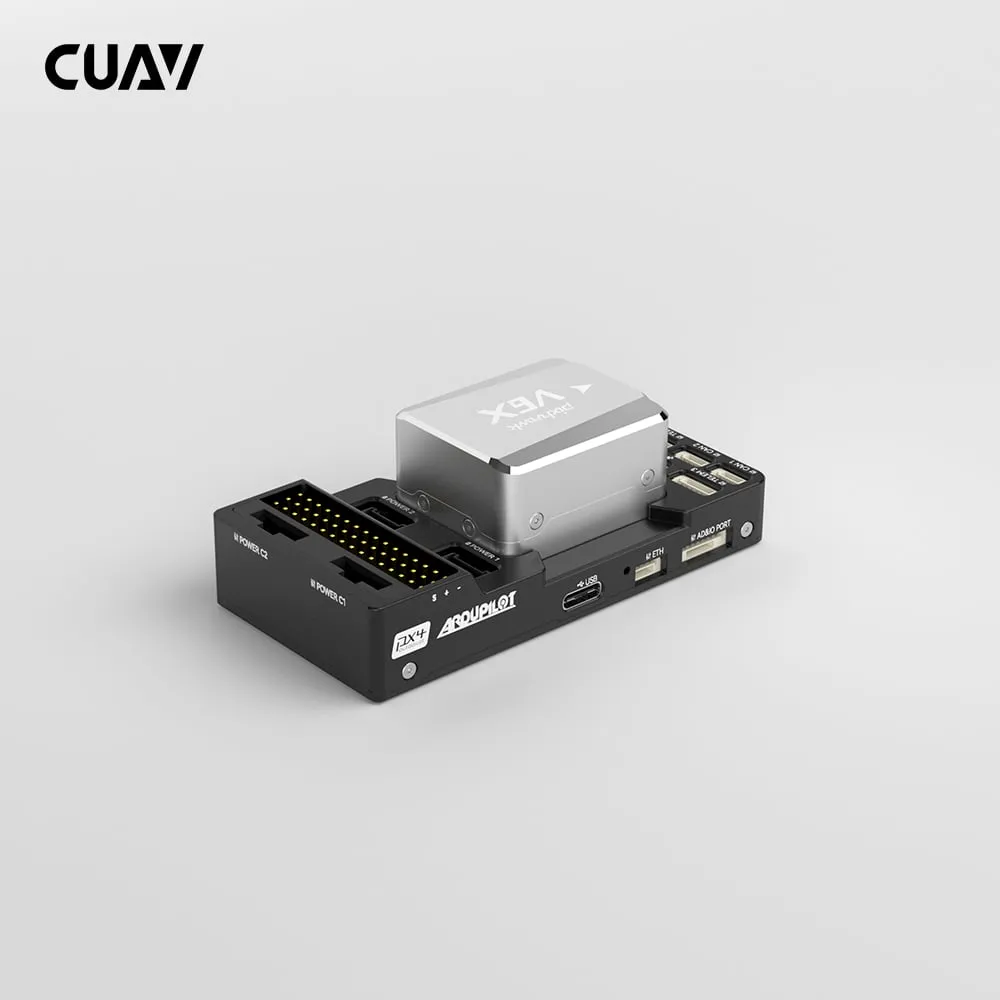
Power inputs: 2 DroneCAN, 2 SMBus/I2C
Operating voltage: 4.75-5.7 V
USB: Type-C plus JST GH1.25
Weight: 99 g (43 g core, 56 g baseboard)
Operating temperature: -20 to 85 °C
Firmware: PX4, ArduPilot
The baseboard does not read analog battery monitors, so pair the V6X with a DroneCAN or I2C/SMBus digital power module. With four power inputs, you can connect two power modules for a redundant supply.
| FC Processor | H7 |
|---|---|
| Gyro | ICM42688P, BMI088, ICM20649 |
| Made in India | No |
| Brand | CUAV |
| Supported Firmware | ArduPilot, PX4 |
| Barometer | Yes |
| UARTs | 6 |
| Weight | 99 g |
| Compass Included | Yes |
| Motor Outputs | 16 |
From builders
Reviews
No reviews yet — be the first to write one.
Compatible
Complete your build
Related