PX4 & Pixhawk Flight Controllers
PX4 & Pixhawk Flight Controllers
36 products
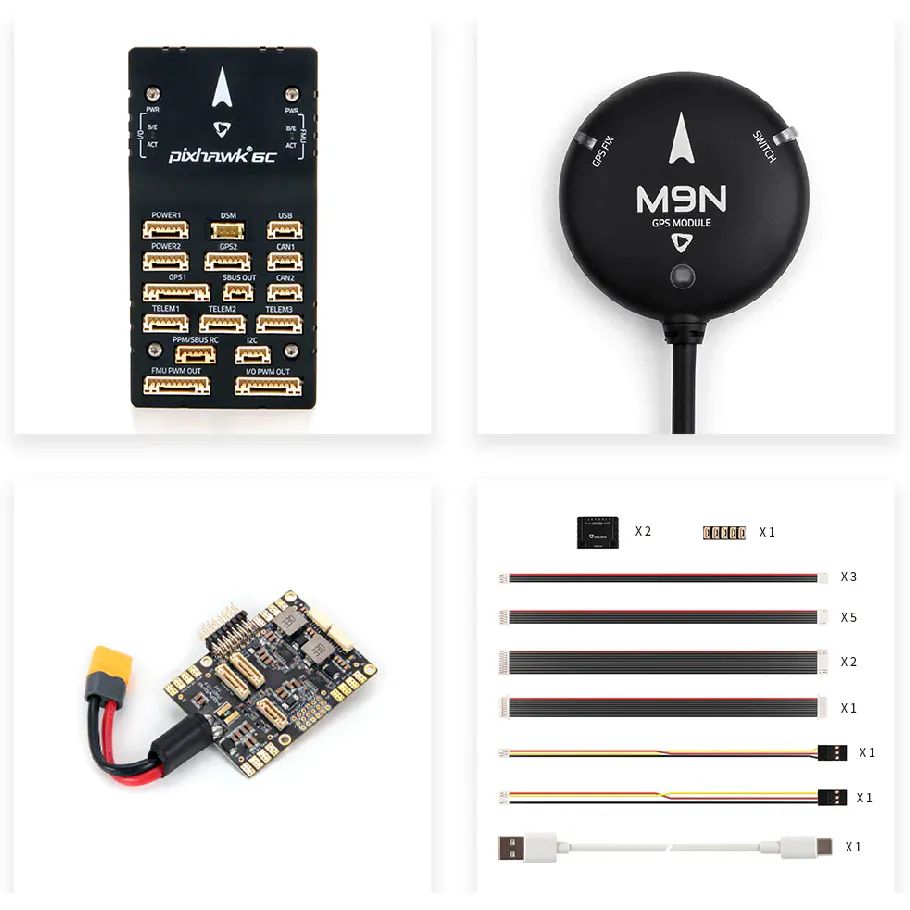
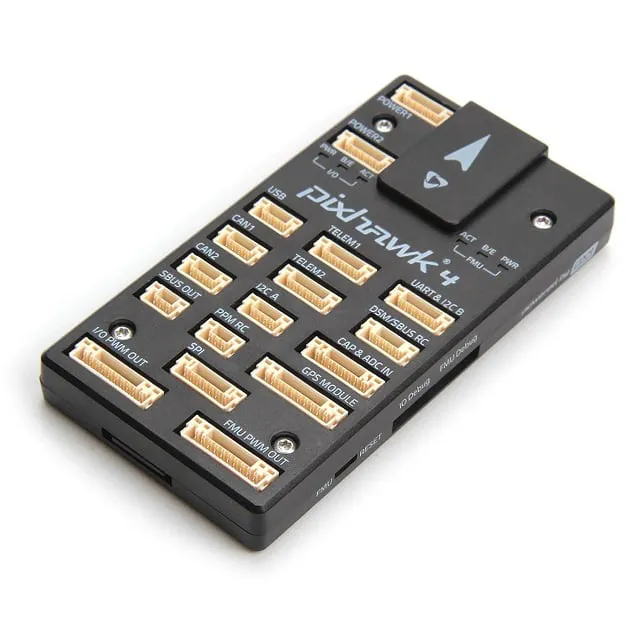
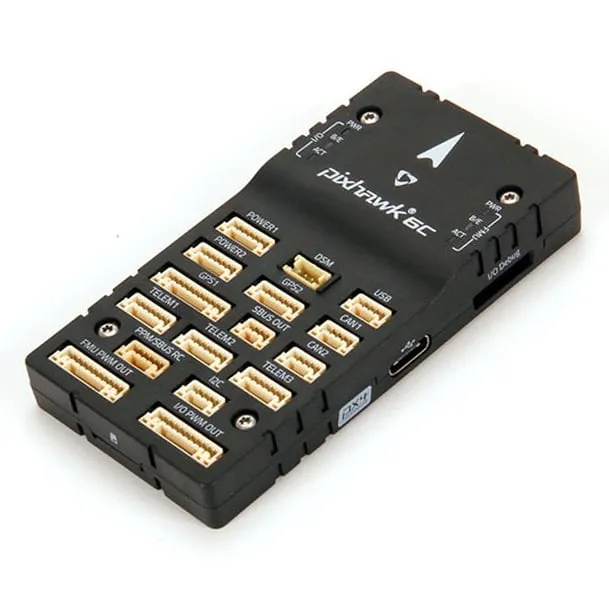
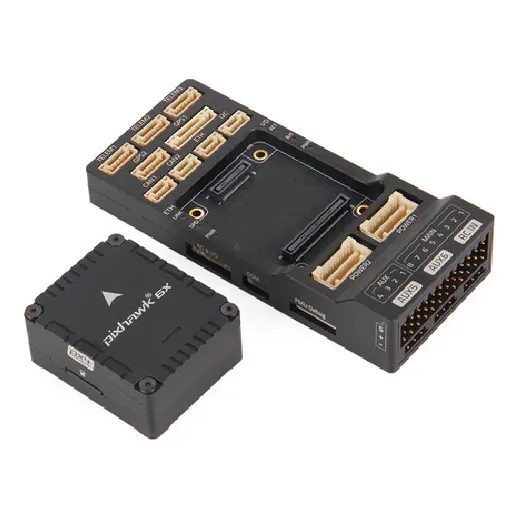
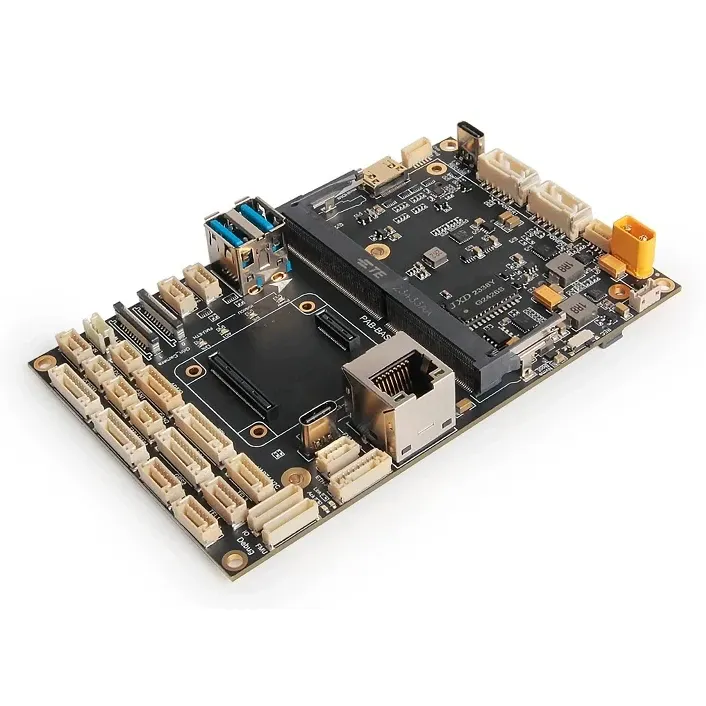
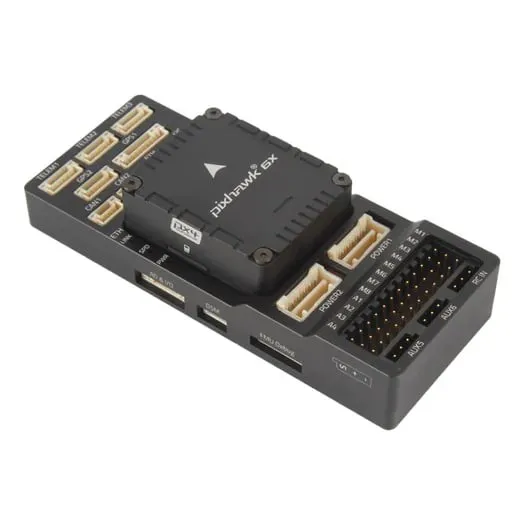


PX4 is the open-source autopilot behind the Pixhawk standard: autonomous missions, redundancy, companion computers and the ecosystem used in survey, agriculture, delivery and research drones. This page collects every flight controller in our range that runs PX4 — from the Pixhawk 2.4.8 used in engineering-college builds to the Holybro Pixhawk 6X and CubePilot Cube Orange+ found in commercial UAVs. Almost all of them run ArduPilot as well, so the choice is about sensors, connectors and the airframe rather than firmware alone.
How to choose a PX4 autopilot
Pixhawk-standard boards share the Pixhawk connector pinouts (JST-GH on current models), so GPS units, power modules and telemetry radios move between boards. The differences are processor generation, sensor quality and the carrier board's I/O.
- Generation: Pixhawk 2.4.8 (FMUv2, STM32F4) is the entry point for learning and small DIY quads. Pixhawk 6C and 6X (FMUv6) and the Cube Orange+ (H7) are the current commercial standard with far more memory and better IMUs.
- Redundancy: 6X and Cube Orange+ carry three IMUs and two barometers with vibration isolation; 6C and 2.4.8 carry fewer.
- Carrier board: Cube modules plug into a carrier — the standard set here includes an ADS-B carrier; Holybro's CM4 baseboard puts a Raspberry Pi companion under the 6X.
- Airframe support: PX4 and ArduPilot both fly multirotors, planes, VTOLs and rovers from the same board.
What we stock
Holybro Pixhawk 6C in aluminium and plastic cases, the Pixhawk 6X Standard Set v2B and the RPi CM4 baseboard bundle with a 6X and PM03D power module; CubePilot's Cube Orange+ standard set with ADS-B carrier and the Cube Orange Plus module on its own; the Pixhawk 2.4.8 PX4 32-bit autopilot for DIY F450 and S500 builds; Radiolink PIX6; SIYI N7 with GPS; the Indian-made ZUPPA Elevate and EZFly autopilots for survey and agriculture drones; and two compact boards that run PX4 alongside Betaflight and INAV — the MicoAir NxtPX4 V2 Mini and Matek H743-Mini V3.
Compatibility
A Pixhawk build needs a GPS with compass (M10 or M9N modules with the Pixhawk connector), a power module for voltage and current sensing, a telemetry radio for ground-station use and a receiver — SBUS, CRSF and ELRS all work. Motors run through standard PWM ESCs or DShot on newer boards.
Flash PX4 through QGroundControl, or ArduPilot through Mission Planner, over USB; check each board's supported-firmware list before you flash.
Frequently asked questions
- PX4 or ArduPilot?
- Both run on the boards here. PX4 has a cleaner architecture and strong companion-computer and research support; ArduPilot has the larger feature set for missions and unusual airframes. For a first build, either works; choose by the community you will lean on.
- Is the Pixhawk 2.4.8 still worth buying?
- For learning, college projects and simple DIY quads on F450 or S500 frames, yes: it is inexpensive and well documented. Its older F4 processor and limited memory mean newer firmware leaves features out, so for commercial work choose a Pixhawk 6C, 6X or Cube Orange+.
- What else do I need with a Pixhawk flight controller?
- A GPS and compass module, a power module, a receiver, a telemetry radio for the ground station, and ESCs and motors for the airframe. Some sets bundle a power module or GPS, so check each listing's contents; a bare board or Cube module comes without them.