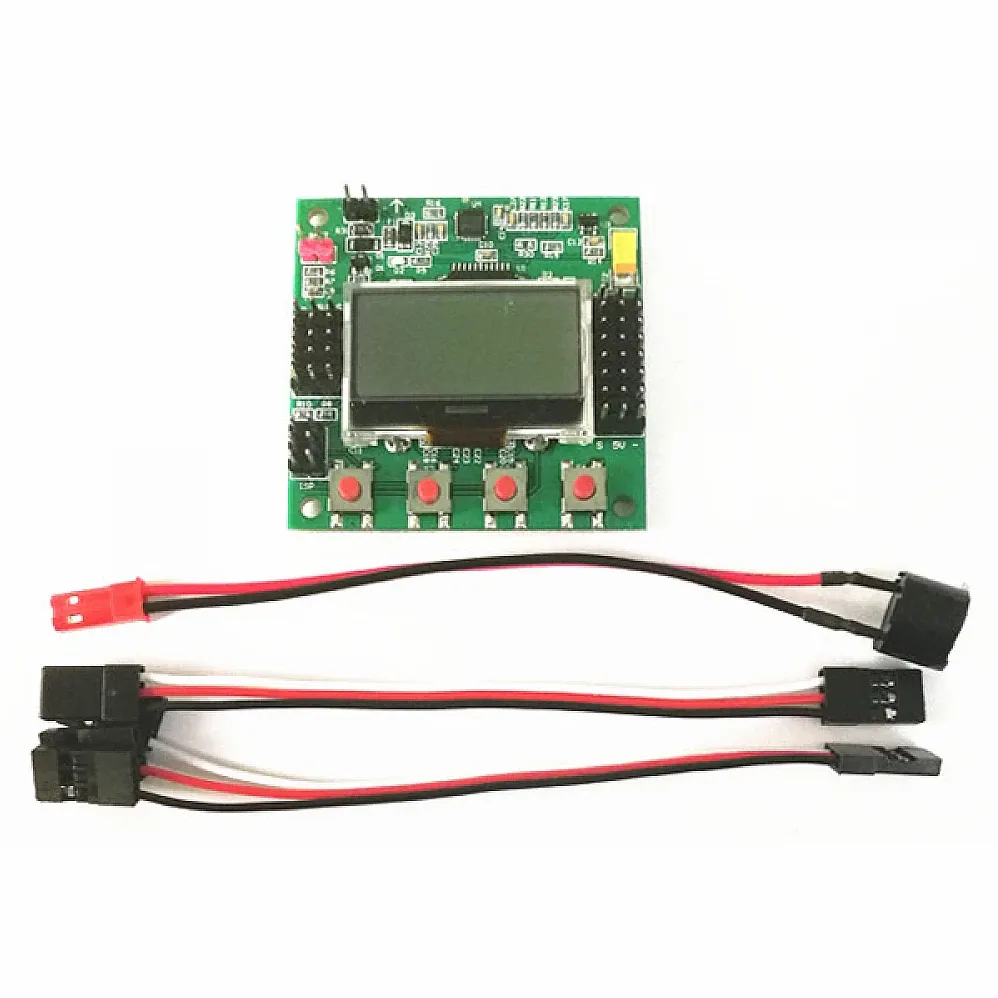
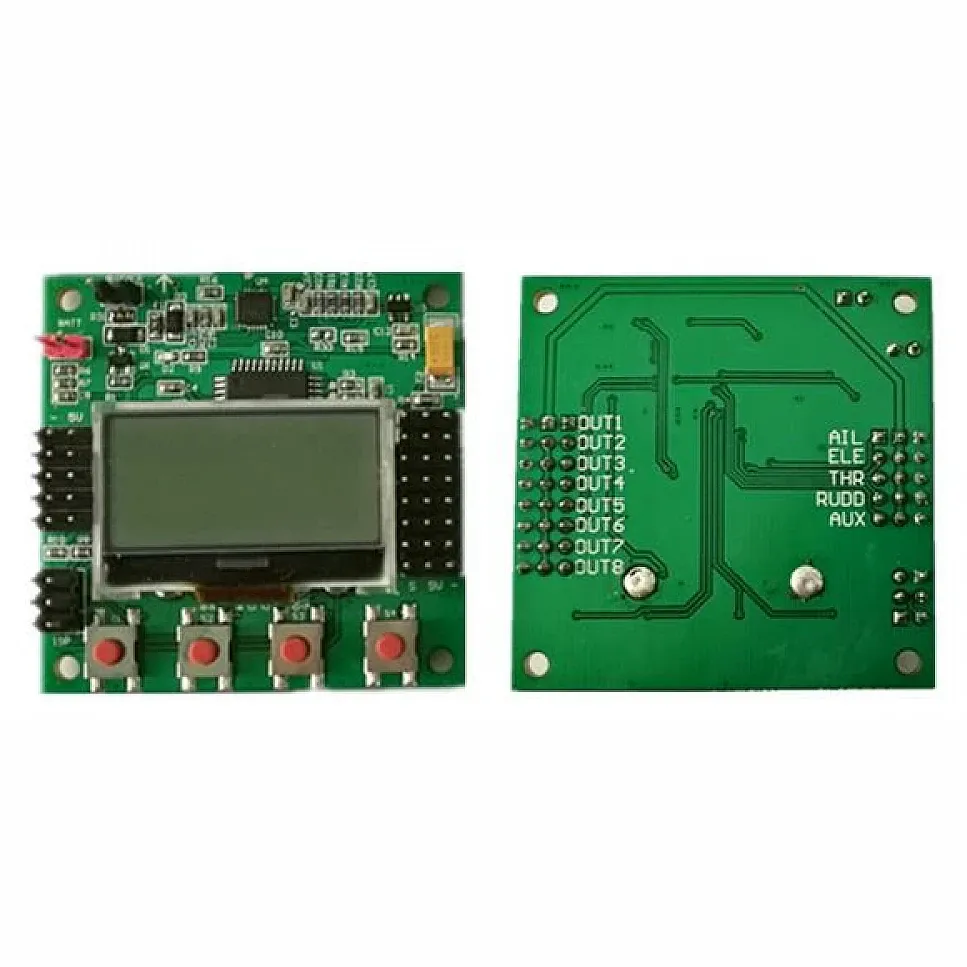
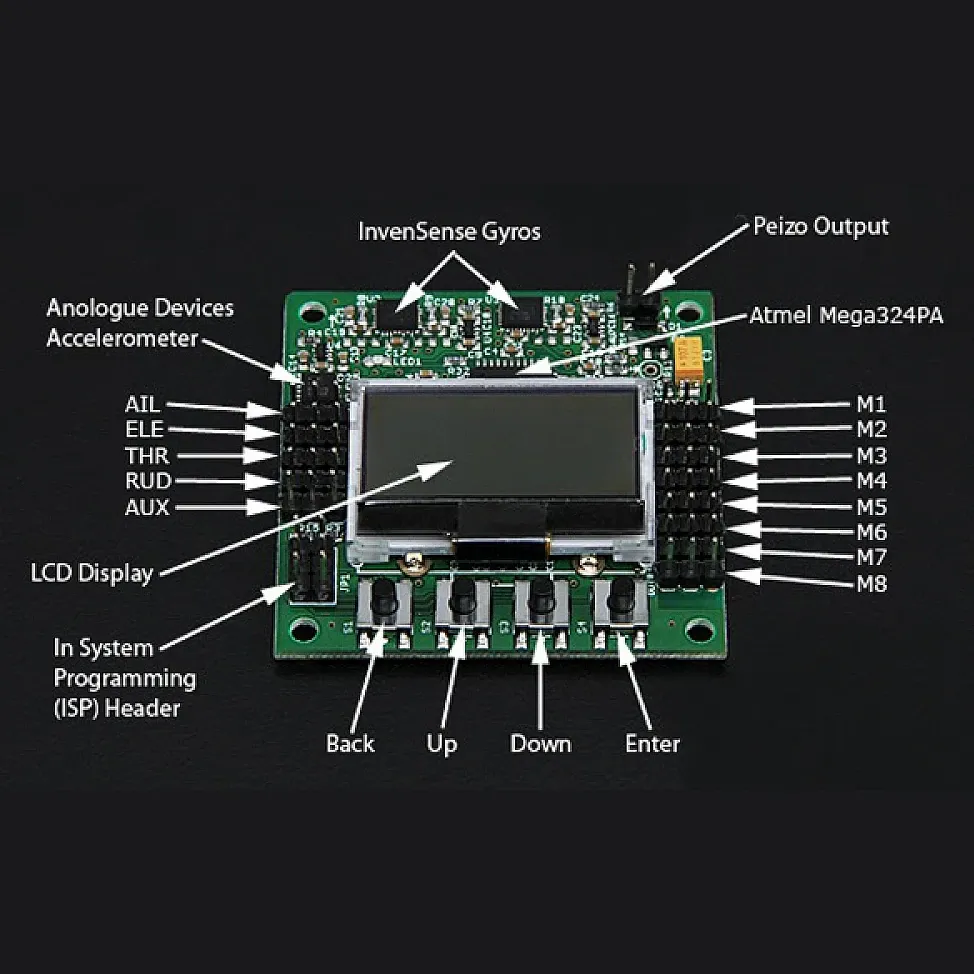
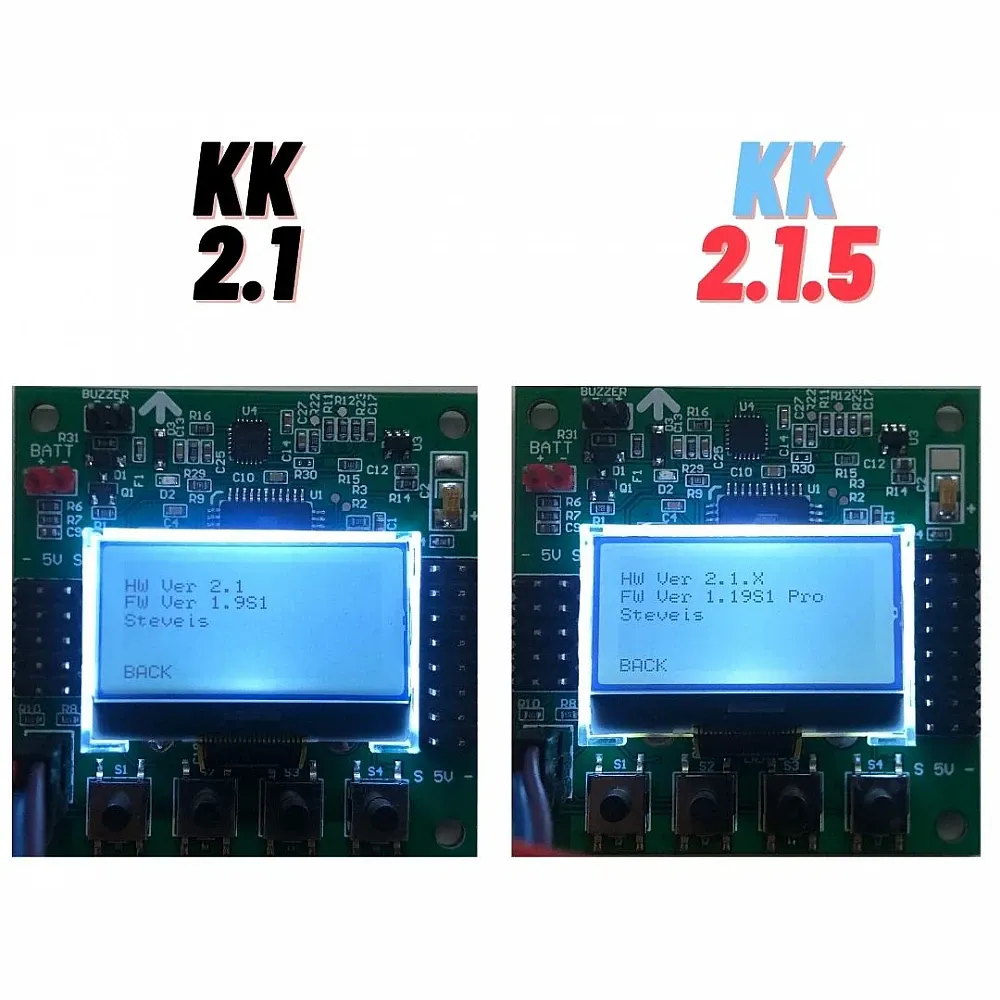
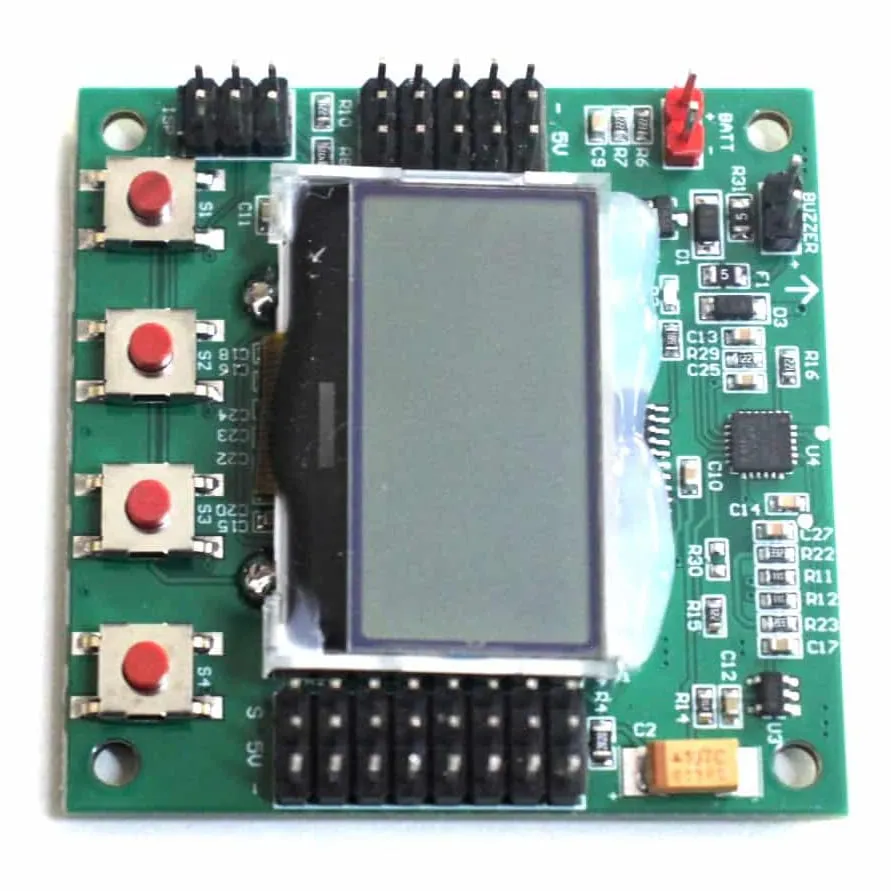
KK2.1.5 LCD Multirotor Flight Controller (MPU6050, ATmega644PA)
SKU KK215-LCD-FC
Free shipping. Pan India delivery from Gurugram, Haryana.
Ships within 3–4 business days — quality-checked in Gurugram before dispatch
Questions about this part? Ask us on WhatsApp- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
The KK2.1.5 is a self-contained multirotor flight controller with a built-in LCD and setup menus, so a first build can be configured at the field without a PC. It suits beginners, students and hobbyists building tricopters, quads, hexes and octos on classic DIY frames.
Key features
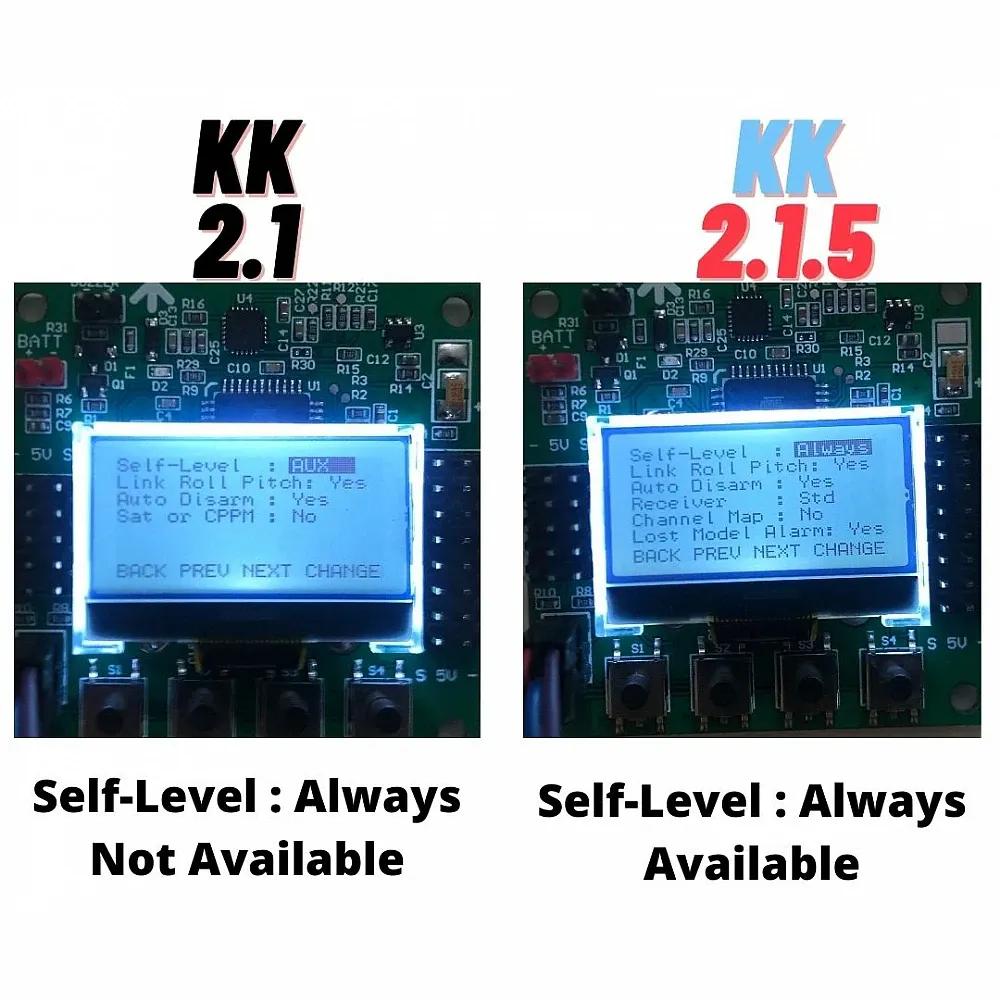
MPU6050 gyro/accelerometer with an auto-level self-levelling mode
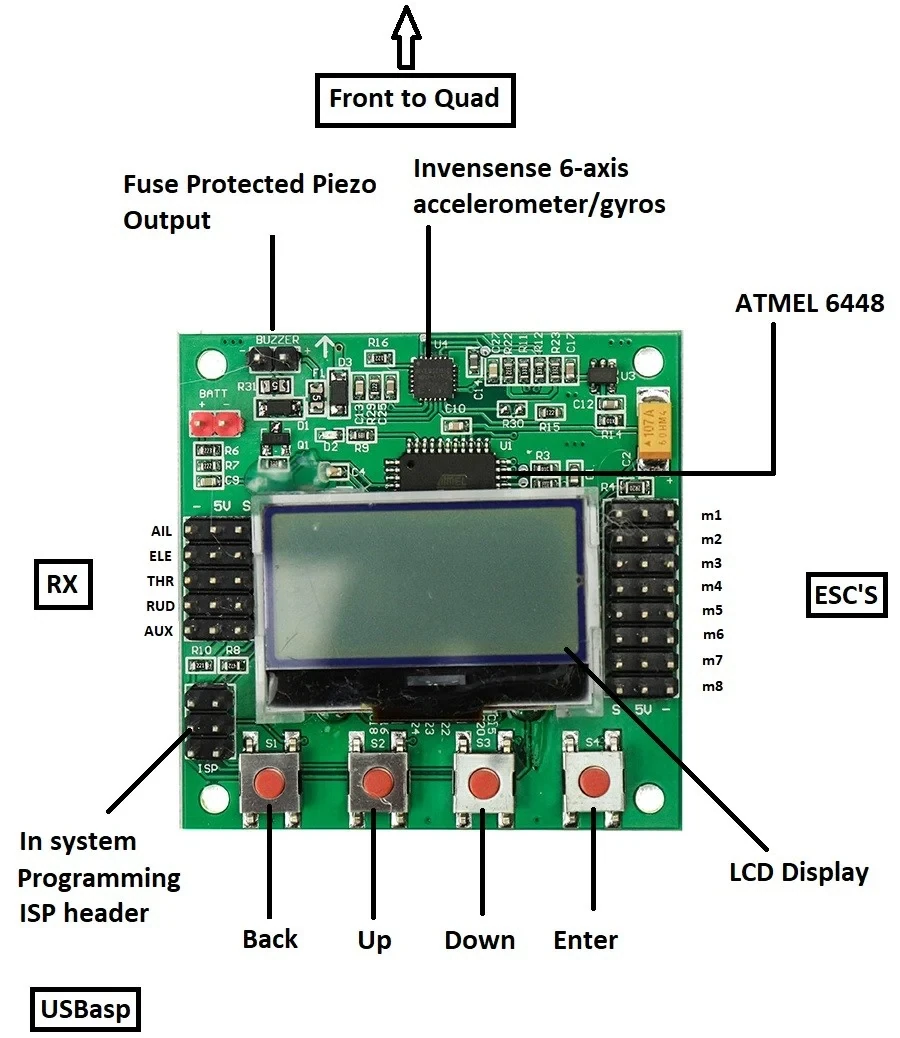
Atmel ATmega644PA 8-bit microcontroller with 64 KB of memory
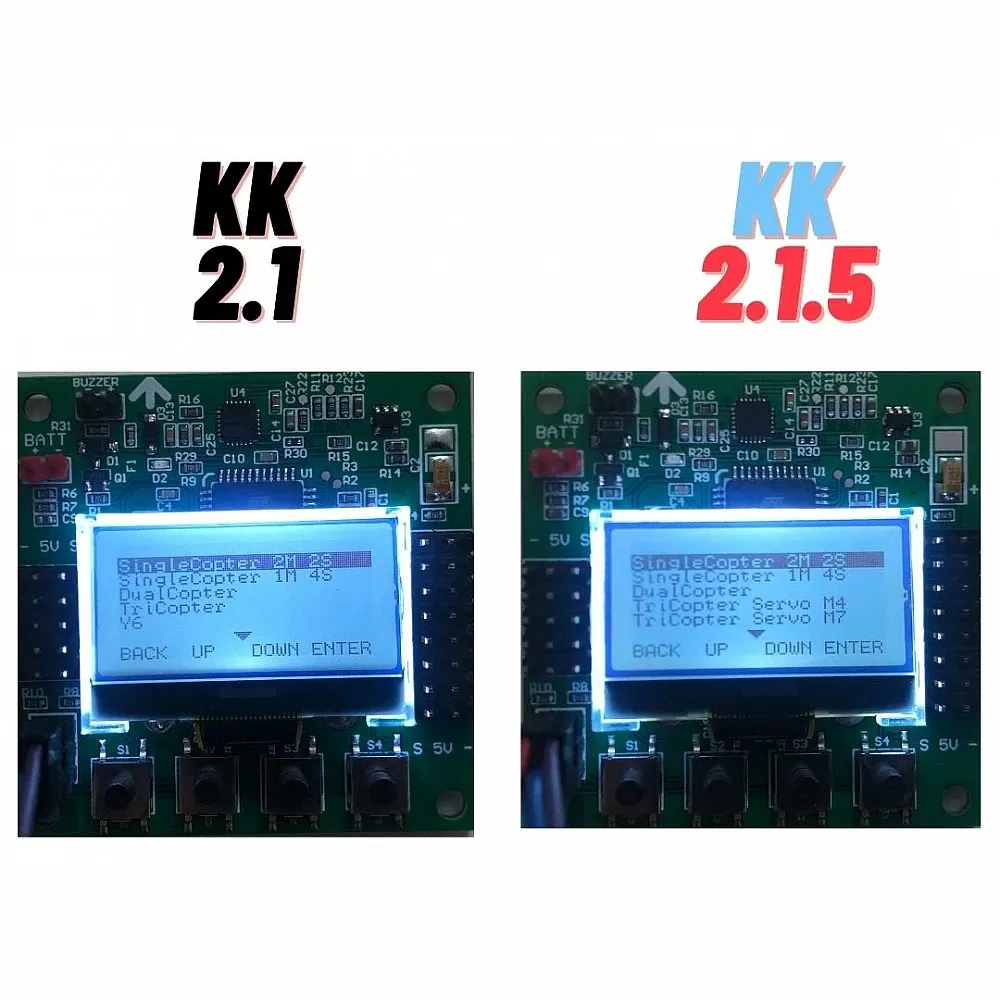
Firmware v1.6 pre-loaded with dual-, tri-, Y6, quad, hex and octo (+ and X), X8, H6, H8, V6, V8, flying-wing and single-copter layouts, plus a Mixer Editor for custom mixes
On-screen prompts walk through motor layout, prop direction, ESC calibration and radio calibration
Polarity protection on the voltage-sense header and a fuse-protected buzzer output
Specifications
Processor: Atmel ATmega644PA
Gyro/accelerometer: InvenSense MPU6050
Input voltage: 4.8–6.0 V
Receiver input: 1520 µs PWM, 5 channels
ESC output: 1520 µs PWM
Programming port: standard 6-pin AVR
Board size: 51 × 51 × 12 mm
Weight: 21 g including piezo buzzer
The board runs on 4.8–6.0 V, so power it from an ESC's BEC or the receiver bus, never straight from the flight pack. It reads separate PWM channel leads, so pair it with a PWM receiver rather than a serial-only SBUS or CRSF unit. There is no GPS support, so position hold and return-to-home are not available. Button colour varies between batches.
| FC Processor | ATmega644PA |
|---|---|
| Gyro | MPU6050 |
| Made in India | No |
| Brand | Generic |
| Weight | 21 g |
From builders
Reviews
No reviews yet — be the first to write one.
Compatible
Complete your build
Related