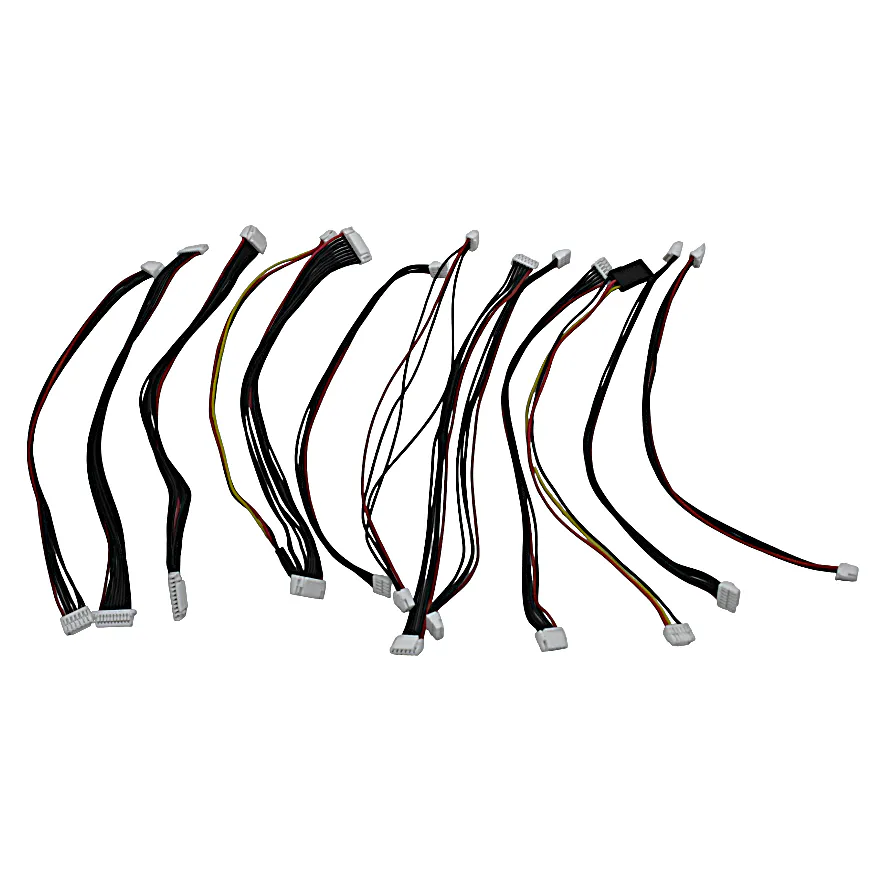
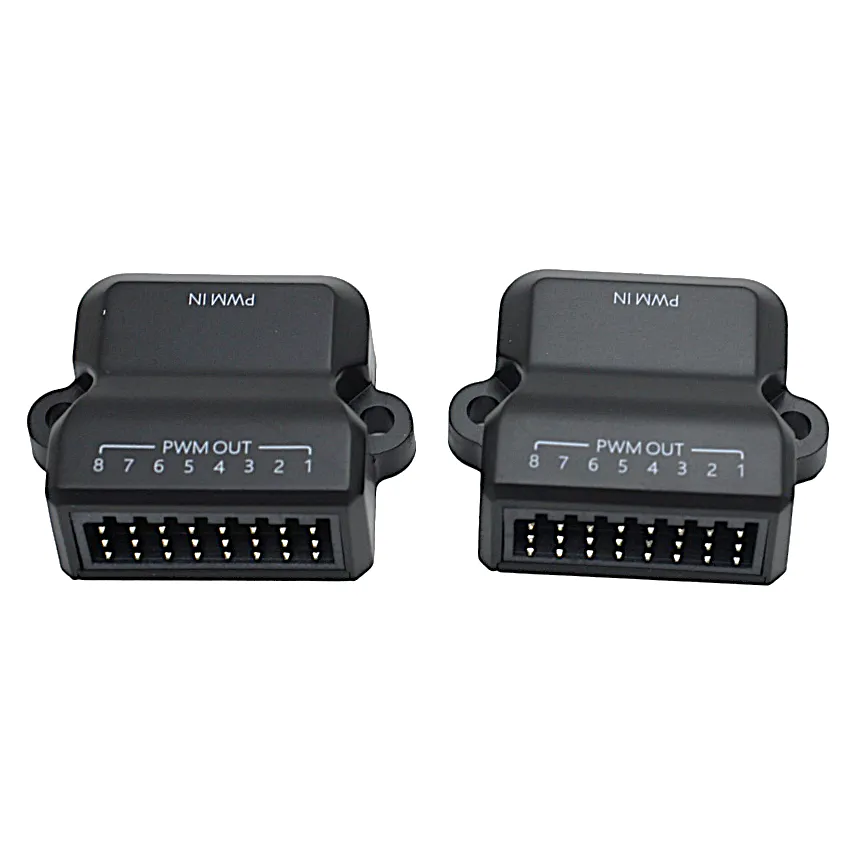
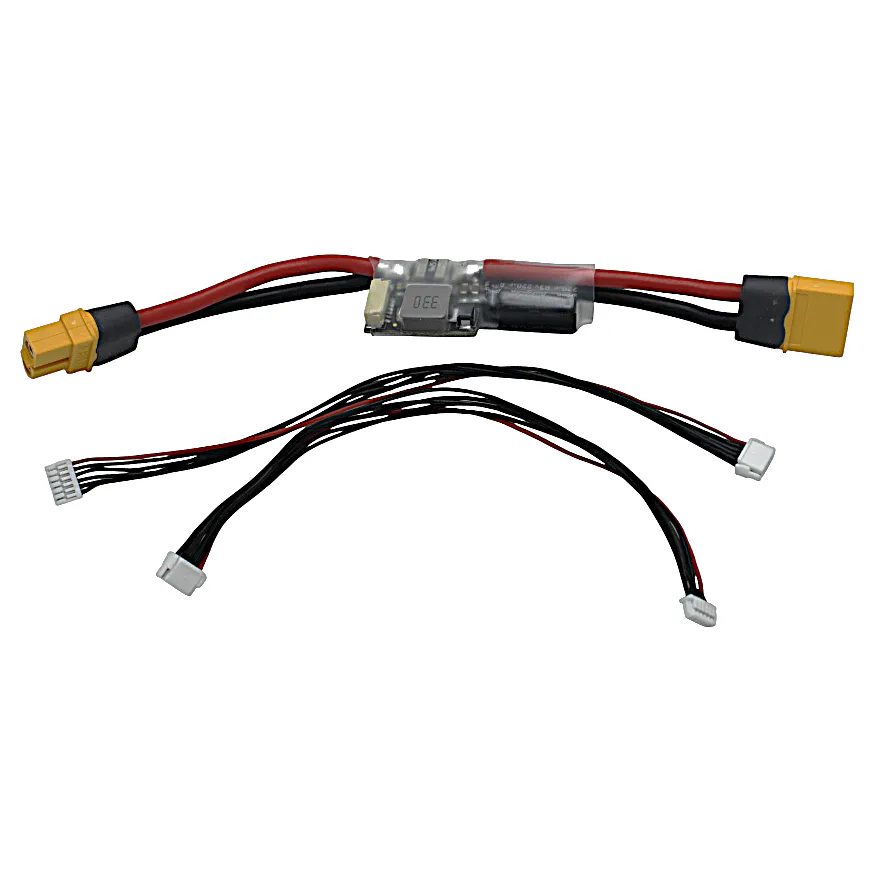
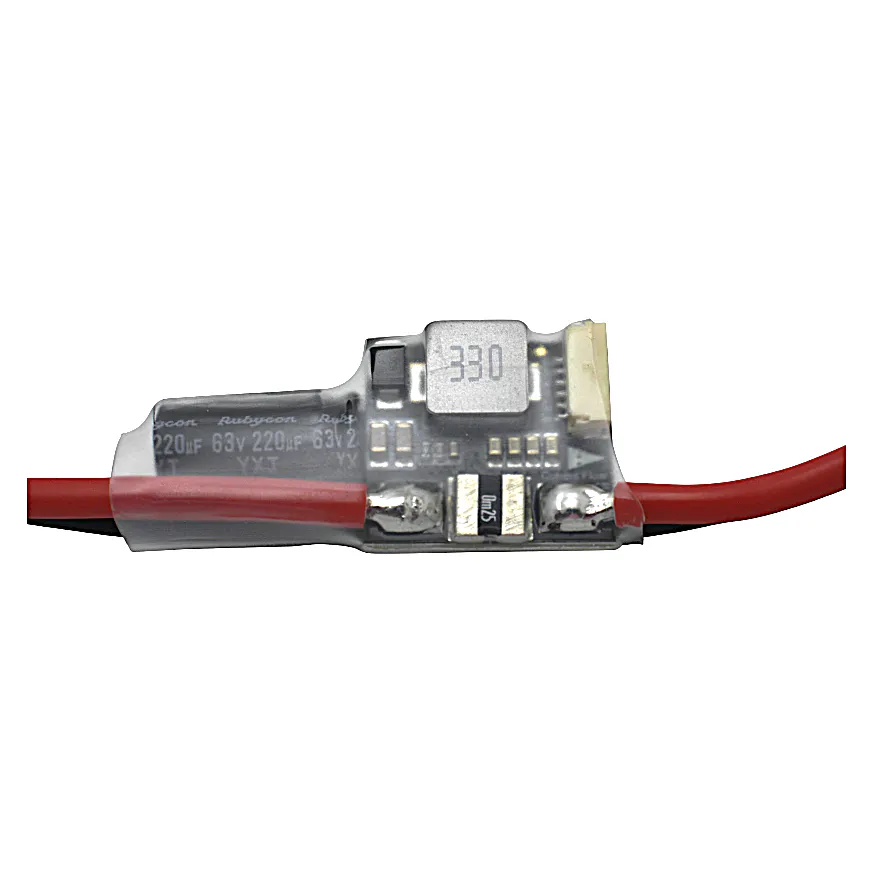
Holybro Pixhawk 6C Flight Controller with PM02 Power Module
₹33,399Incl. GST
SKU HOLYBRO-PIXHAWK6C-PM02
Integrated VTX: NoIntegrated Receiver: NoFC Processor: H743Gyro: ICM42688P, BMI088
Free shipping. Pan India delivery from Gurugram, Haryana.
Ships within 3–4 business days — quality-checked in Gurugram before dispatch
Questions about this part? Ask us on WhatsApp- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
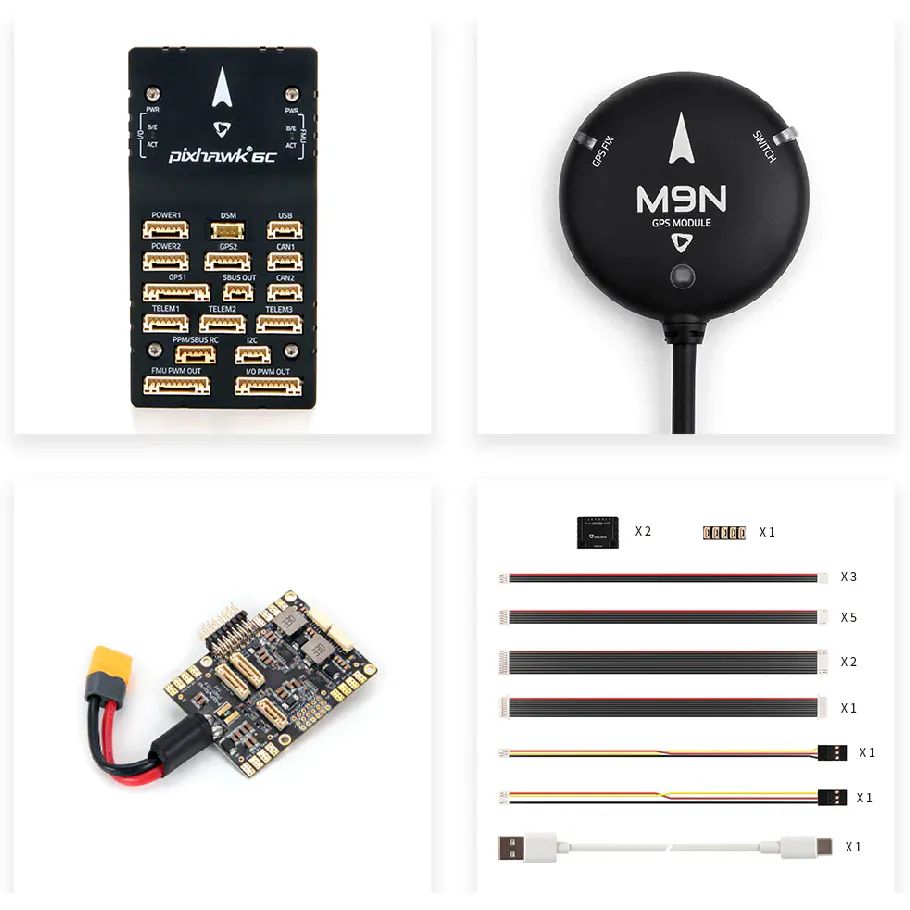
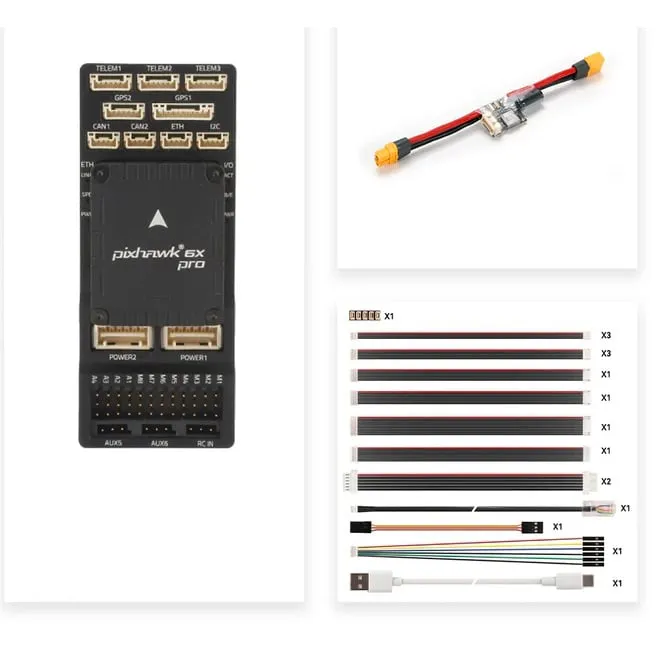
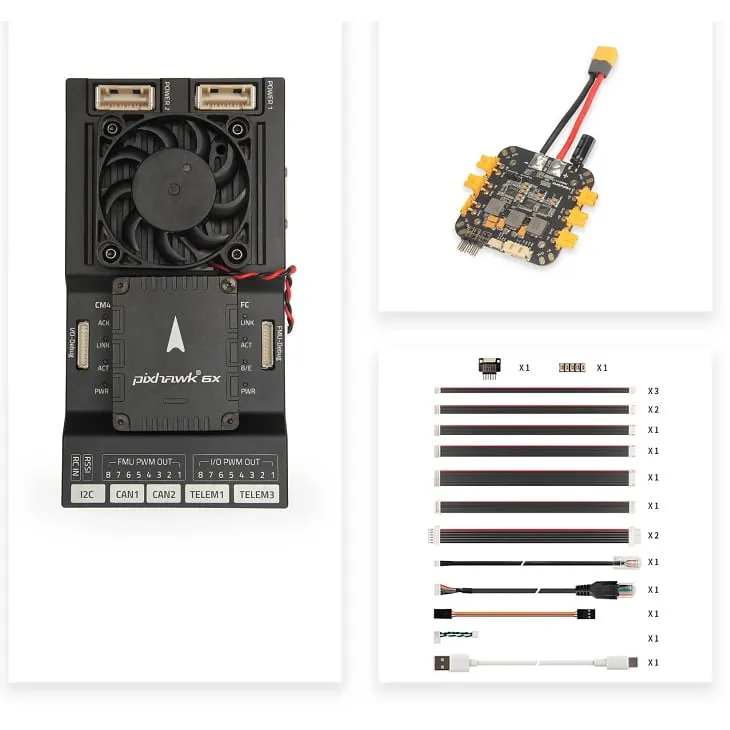
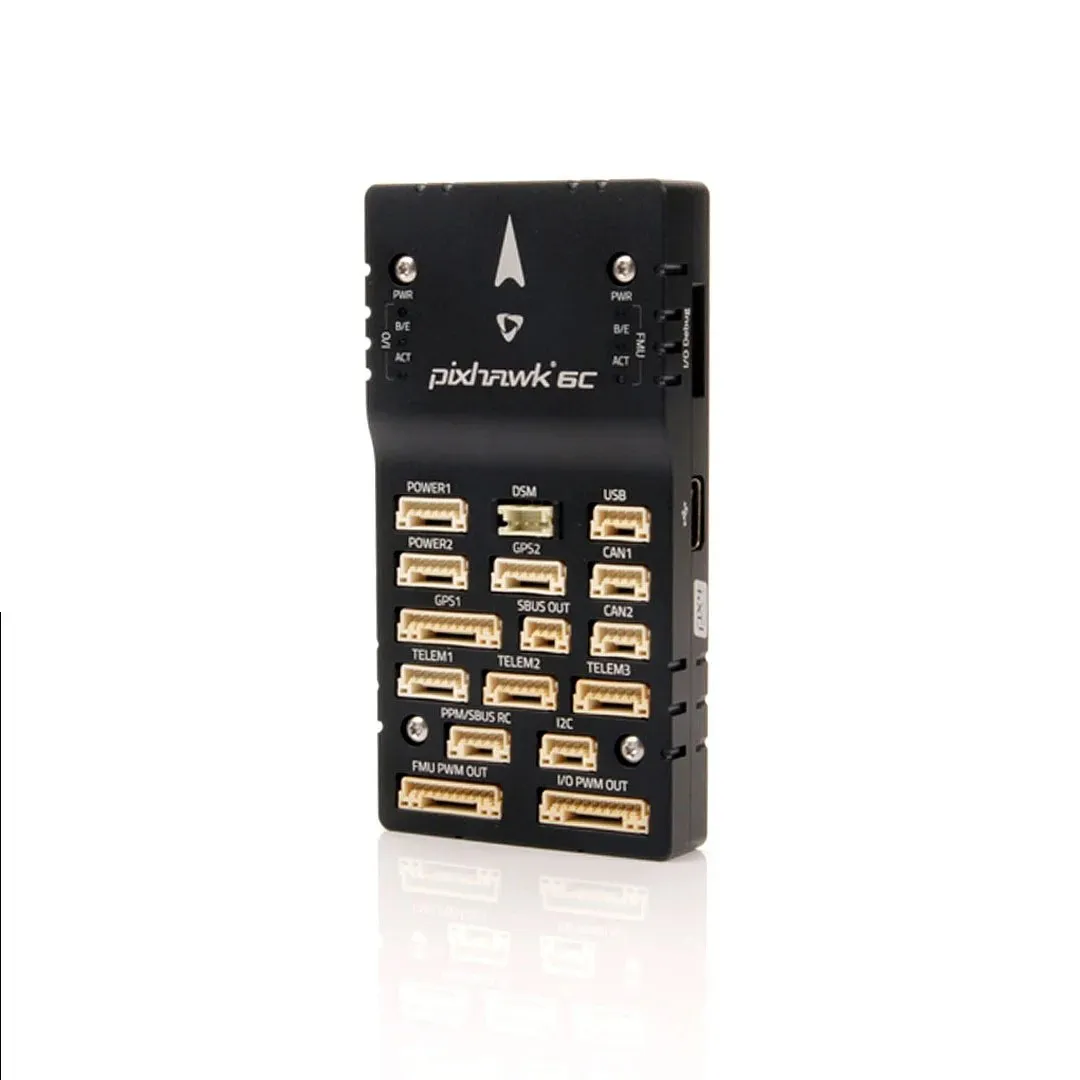
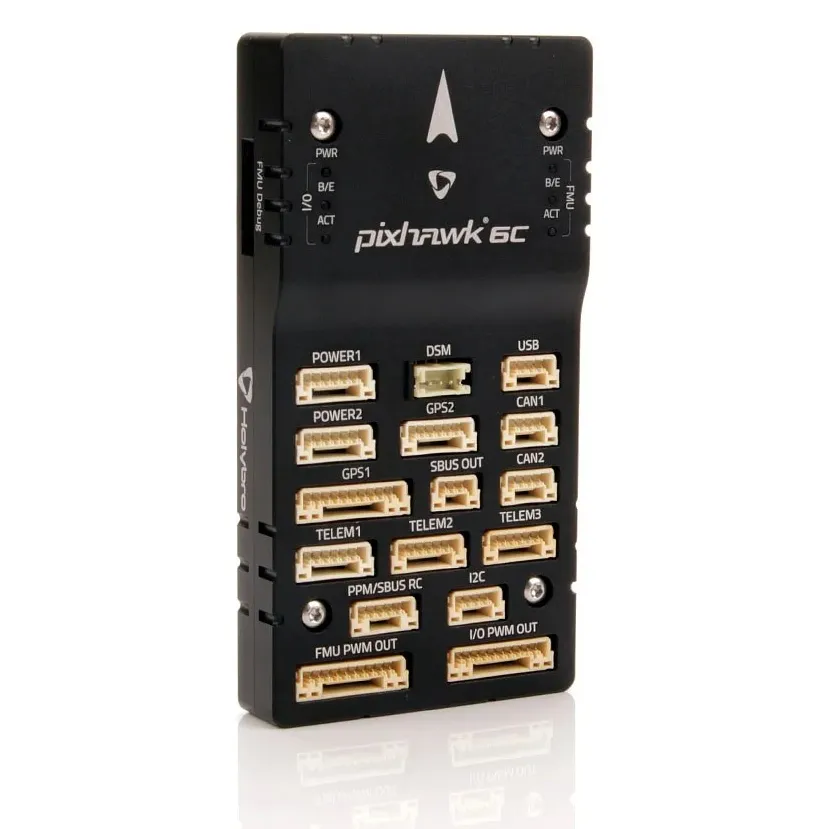
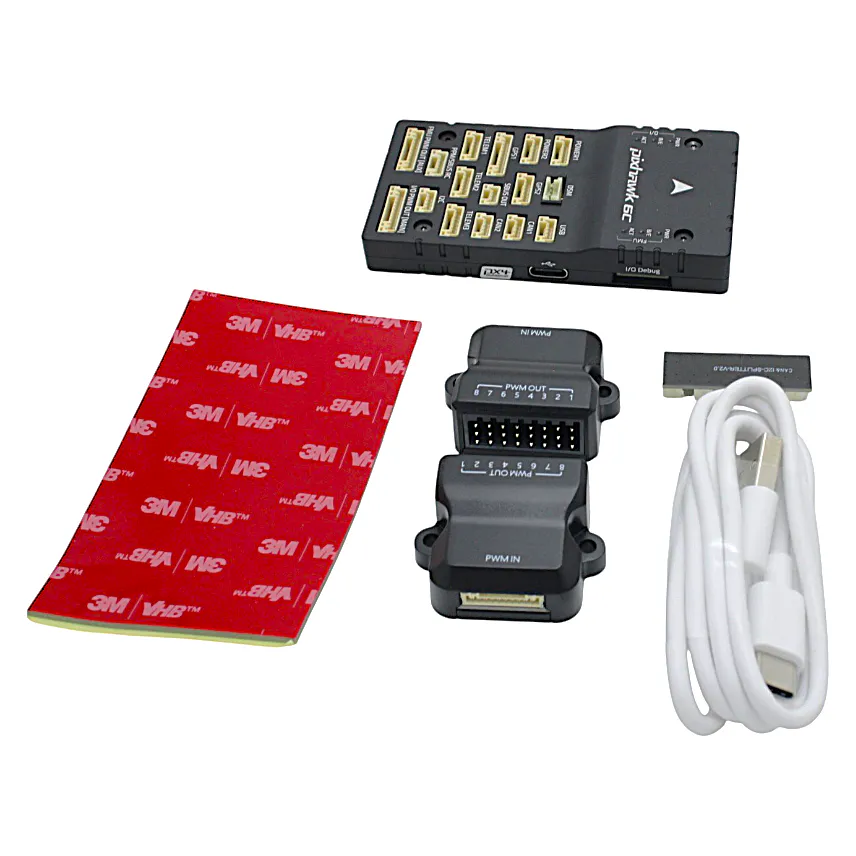
The Holybro Pixhawk 6C is a Pixhawk FMUv6C open-standard autopilot for multirotors, fixed-wings, VTOLs and ground vehicles, supplied here with the PM02 analog power module. It comes with PX4 pre-installed and also runs ArduPilot, which makes it a common choice for survey, research and agricultural builds.
Key features
- STM32H743 main processor at 480 MHz with 2 MB flash and 1 MB RAM, plus an STM32F103 IO co-processor
- Redundant IMUs from InvenSense and Bosch, temperature-controlled by onboard heaters and vibration-isolated
- MS5611 barometer and IST8310 magnetometer on board
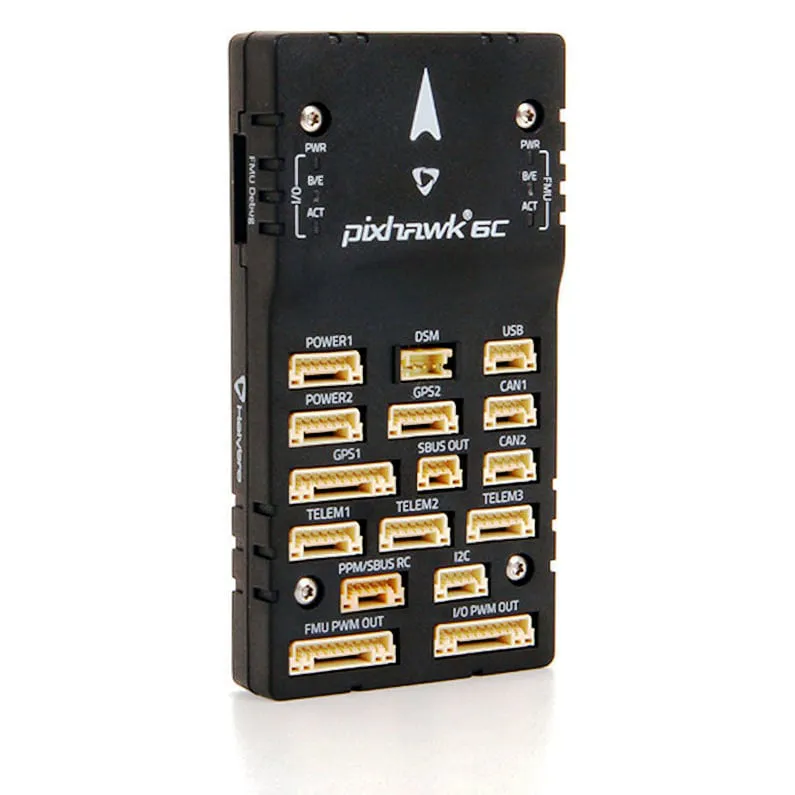
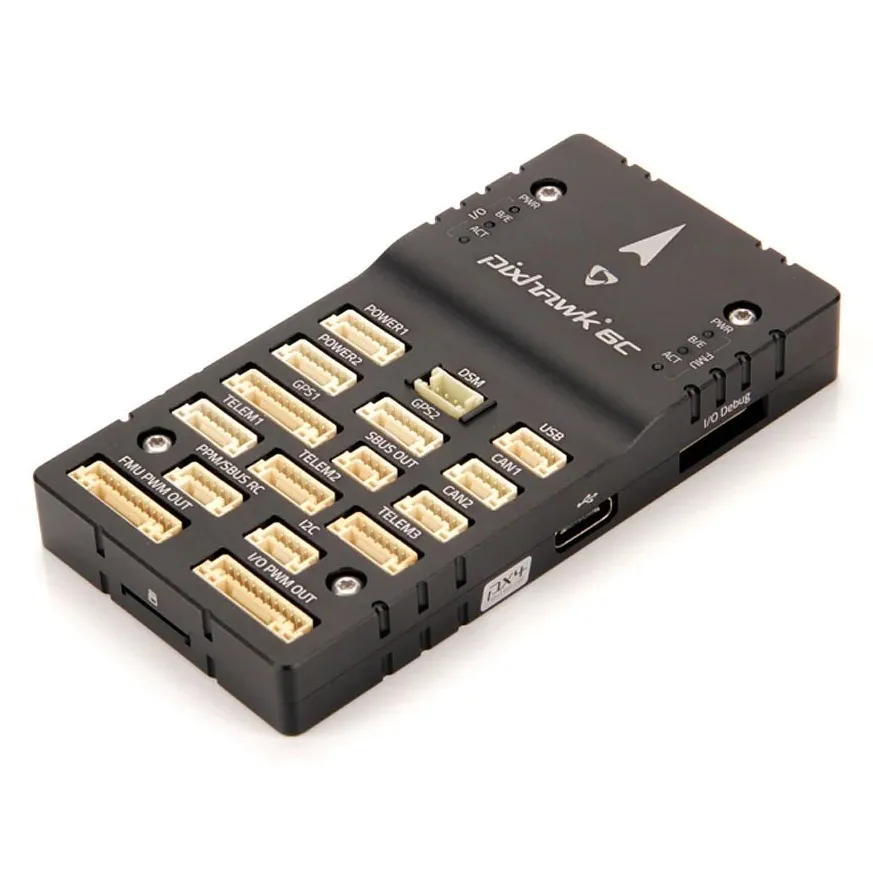
- 16 PWM outputs, two CAN buses, three telemetry ports and two GPS ports
- PM02 supplies the autopilot and reports battery voltage and current to the flight software
Specifications
- FMU processor: STM32H743, Cortex-M7, 480 MHz
- IO processor: STM32F103
- IMUs: ICM-42688-P and BMI088
- Barometer: MS5611
- Magnetometer: IST8310
- Serial ports: Telem1, Telem2, Telem3, GPS1 (with safety switch), GPS2
- PWM outputs: 16 (8 IO + 8 FMU)
- CAN: 2
- Dimensions: 84.8 x 44 x 12.4 mm
- PM02 input: 2-12S LiPo via XT60
- PM02 current: 60 A continuous, 120 A max sensing
- PM02 output: 5.2 V, 3 A
- Firmware: PX4 (pre-installed), ArduPilot
Earlier production used a BMI055 as the second IMU; current boards use the BMI088. Add a GPS module and telemetry radio to complete a mission-ready setup.
| Integrated VTX | No |
|---|---|
| Integrated Receiver | No |
| FC Processor | H743 |
| Gyro | ICM42688P, BMI088 |
| Input Voltage | 2–12S |
| Made in India | No |
| Brand | Holybro |
| Supported Firmware | ArduPilot, PX4 |
| Barometer | Yes |
| UARTs | 5 |
| Compass Included | Yes |
From builders
Reviews
No reviews yet — be the first to write one.
Related