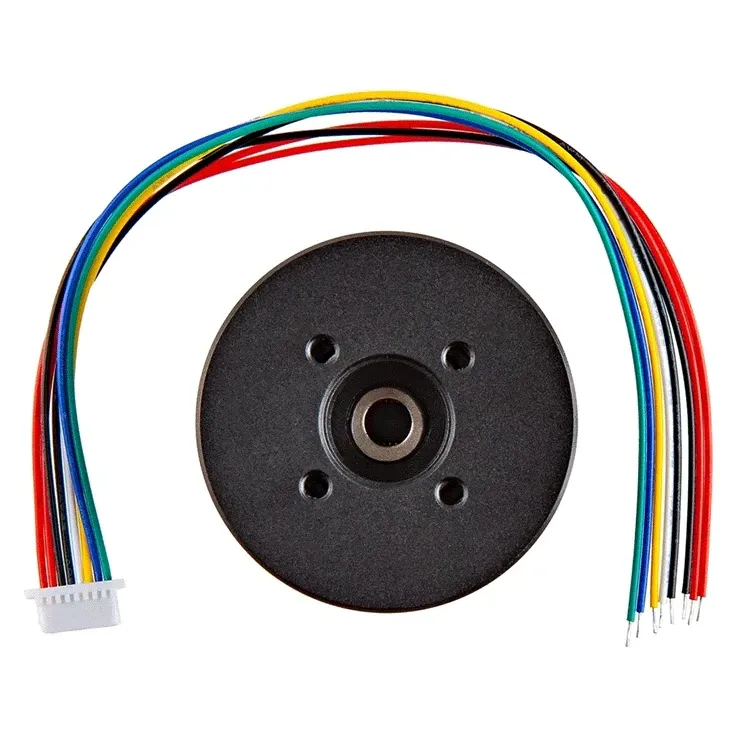
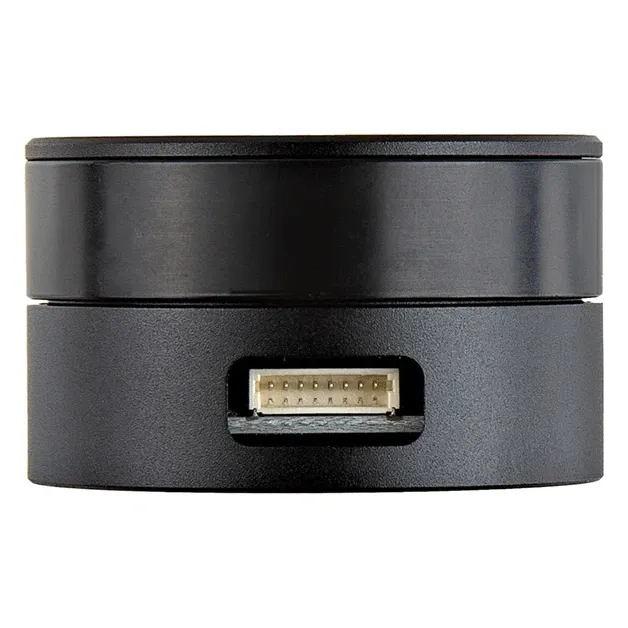
SparkFun Gimbal Servo Motor 12V 467RPM, RS485/
SKU SPARKFUN-GIMBAL-SERVO
Free shipping. Pan India delivery from Gurugram, Haryana.
Ships within 3–4 business days — quality-checked in Gurugram before dispatch
Questions about this part? Ask us on WhatsApp- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
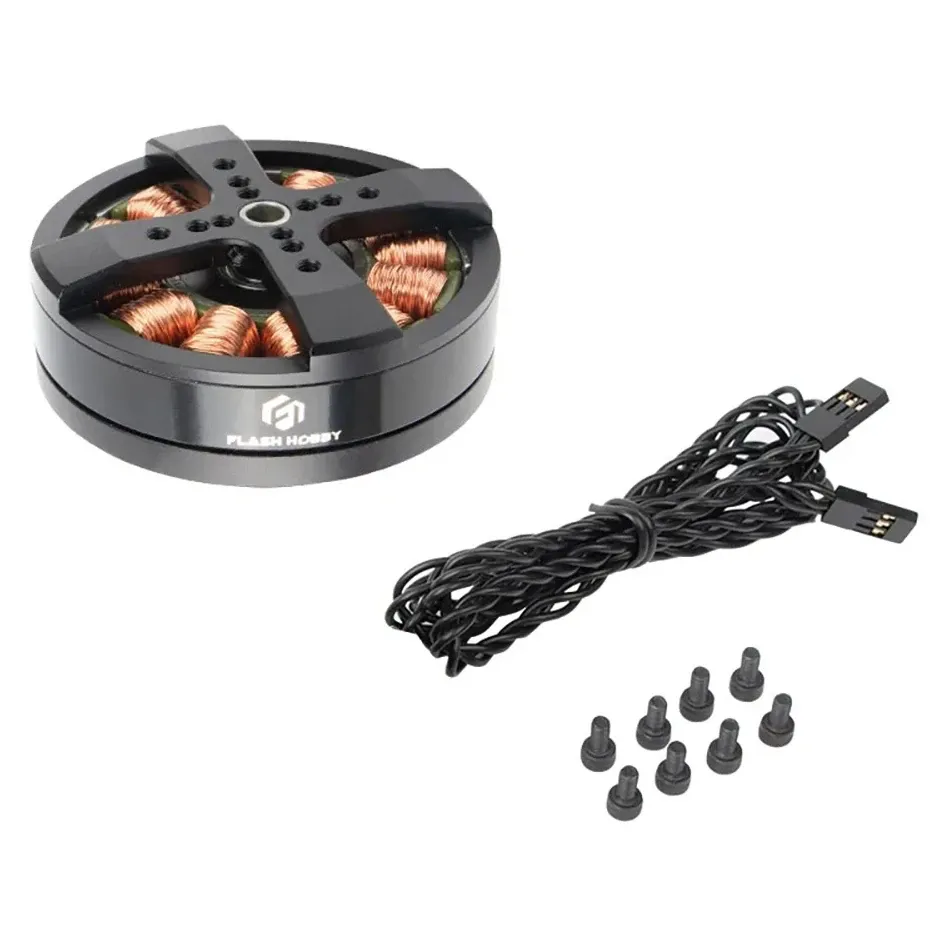
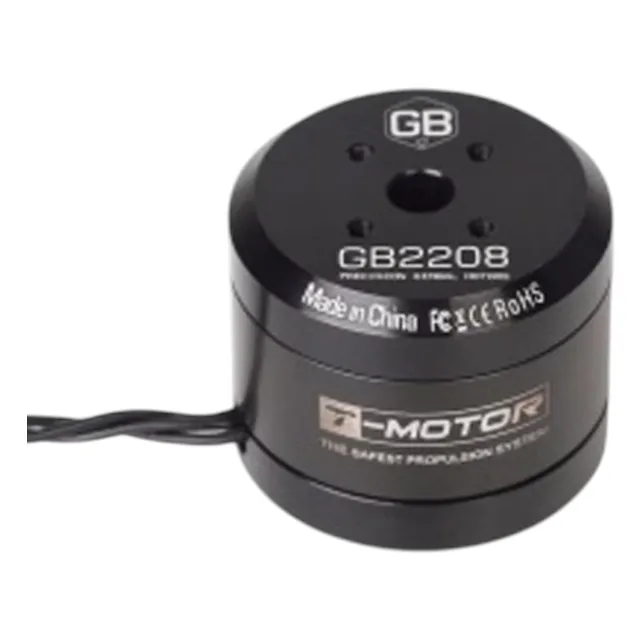
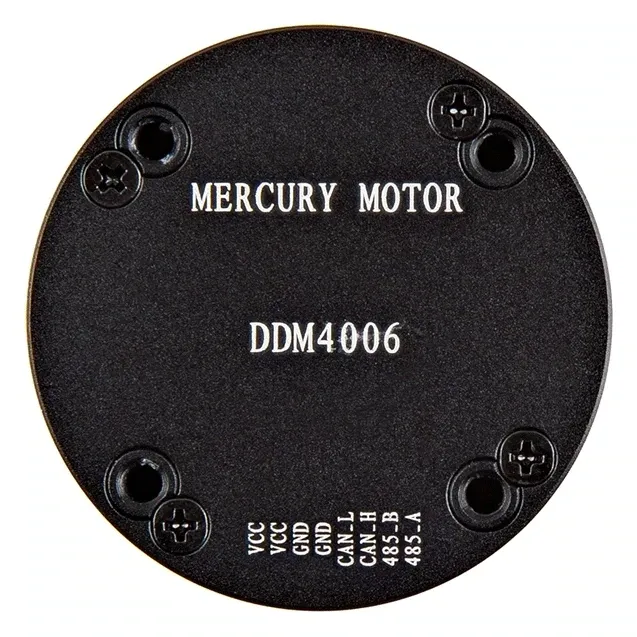
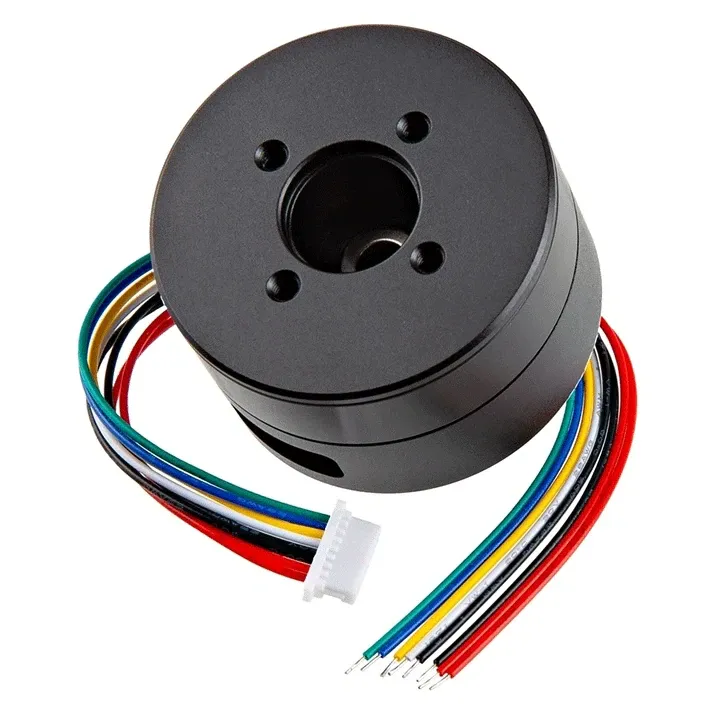
A 40mm brushless gimbal servo with its drive electronics and a 14-bit absolute encoder built in, controlled over RS485 or CAN. Instead of pairing a bare gimbal motor with a separate FOC driver and encoder, you command it over a bus — a tidy fit for robot joints, pan-tilt heads, camera gimbals and precision automation.
Key features
- 14-bit single-turn absolute encoder reports shaft angle within one revolution from power-up
- RS485 and CAN bus interfaces for integration into multi-axis control systems
- 5–28V input range covers 2S to 6S LiPo packs and 12V or 24V bench supplies
- 0.09N·m nominal and 0.15N·m stall torque, 1412RPM maximum speed
- 40 x 24mm body weighing 70g, rated for -20°C to 80°C
Specifications
- Nominal voltage: 12V
- Voltage range: 5–28V
- Nominal current / power: 1.1A / 13.2W
- Stall current: 1.9A
- Speed: 467RPM nominal, 1412RPM maximum
- Torque: 0.09N·m nominal, 0.15N·m stall
- Torque constant: 0.08N·m/A
- Speed constant: 117rpm/V
- Pole pairs: 11
- Phase-to-phase resistance: 3.17Ω
- Phase-to-phase inductance: 0.54mH
- Encoder: Single-turn absolute, 14-bit
- Communication: RS485 / CAN
- Size: 40 x 24mm
- Weight: 70g
- Operating temperature: -20°C to 80°C
You will need an RS485 or CAN transceiver on the host side — a microcontroller or single-board computer with the right interface, or a USB adapter — plus the command protocol from the datasheet to drive it.
| Brand | SparkFun |
|---|---|
| Made in India | No |
| Weight | 70 g |
| Input Voltage | 2–6S |
| KV | 117 KV |
From builders
Reviews
No reviews yet — be the first to write one.
Compatible
Complete your build
Related