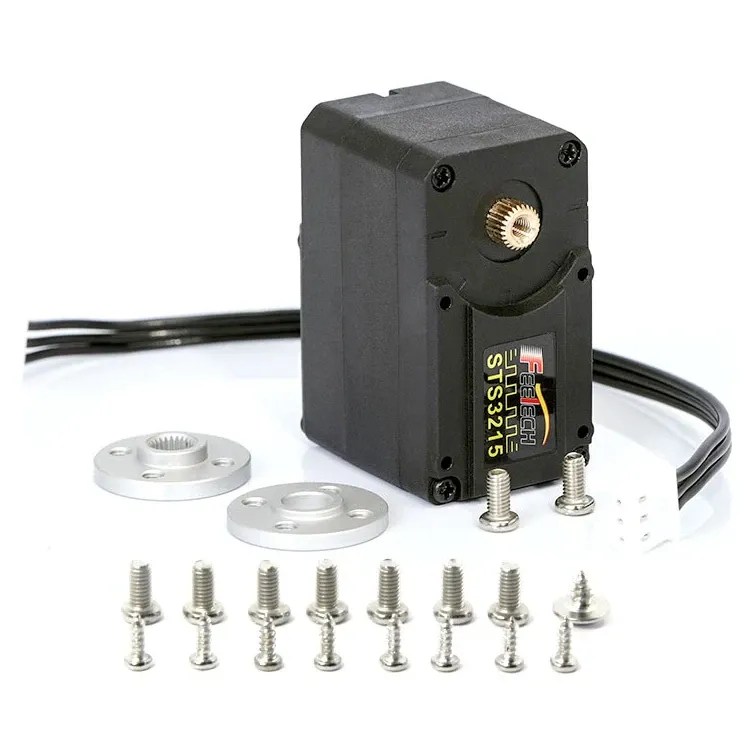
Feetech STS3215 Dual-Axis TTL Serial Bus Servo with Magnetic Encoder
SKU FT-STS3215-C001
Version: 7.4V 19kg, 1:345 (C001)
Free shipping. Pan India delivery from Gurugram, Haryana.
Ships within 3–4 business days — quality-checked in Gurugram before dispatch
Questions about this part? Ask us on WhatsApp- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
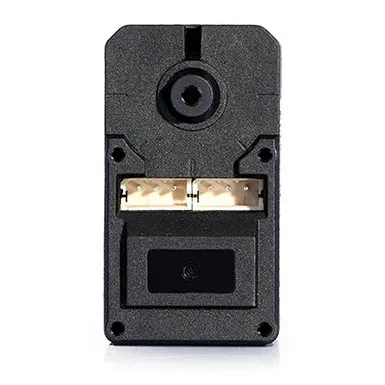
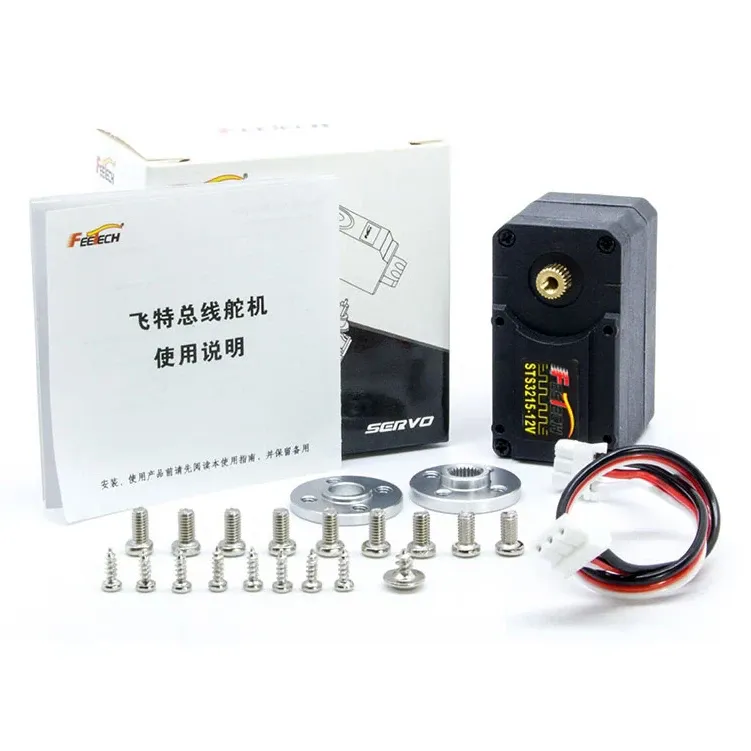
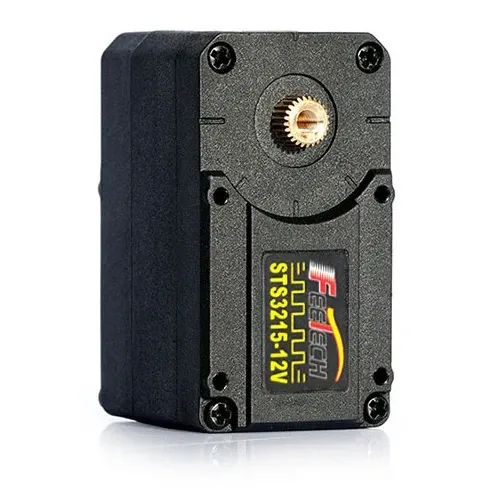
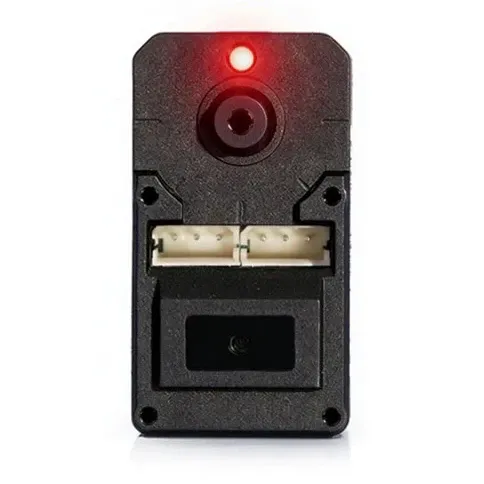
The Feetech STS3215 is the serial bus servo used in the open-source SO-100 and SO-101 LeRobot arms, and a popular choice for any multi-joint arm, gripper or humanoid project. Each unit has a dual-axis output, metal gears, a 12-bit magnetic encoder and feedback over the TTL serial bus, so a whole arm runs from one controller line.
Key features
- Four versions: three 7.4V gear ratios (1:345, 1:191 and 1:147) and a 12V, 30kg version
- 12-bit magnetic encoder: 4096 positions over 360° (0.088° per step), no angle limit
- Copper metal gears with ball bearings
- Daisy-chain IDs 0-253 on one half-duplex TTL bus, with load, position, speed, voltage and temperature feedback
- Dual-axis output with a 25T horn spline for brackets on both sides
Specifications
- C001: 7.4V, 1:345 gear ratio, 19kg-class torque
- C044: 7.4V, 1:191 gear ratio, 16kg.cm stall and 0.116 s/60° (86 RPM) at 7.4V
- C046: 7.4V, 1:147 gear ratio, 14.4kg.cm stall and 0.094 s/60° (106 RPM) at 7.4V
- C018: 12V, 30kg.cm, dual shaft
- Input range (C044/C046): 5-8.4V
- Interface: half-duplex asynchronous serial (TTL), digital packet
- Dimensions (7.4V versions): 45.2 x 24.7 x 35mm
- Weight (7.4V versions): 55g (±1g)
An SO-101 follower arm takes six C001 servos; the 12V C018 is the higher-torque alternative and needs a 12V supply. The SO-101 leader arm uses one C001, two C044 and three C046, because the lower ratios let the arm hold its own weight yet move easily by hand.
| Brand | Feetech |
|---|---|
| Made in India | No |
| Weight | 55 g |
From builders
Reviews
No reviews yet — be the first to write one.
Related