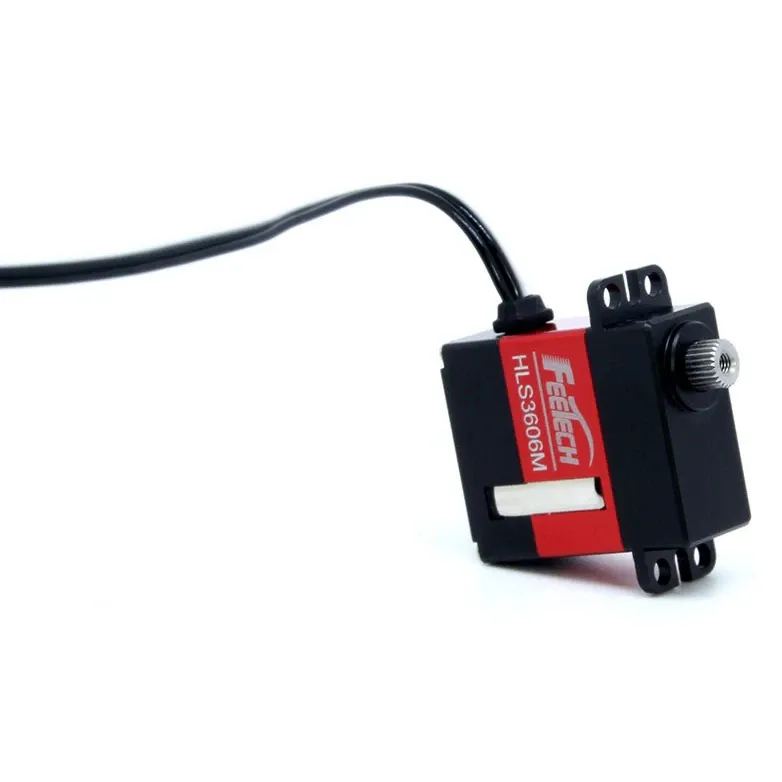
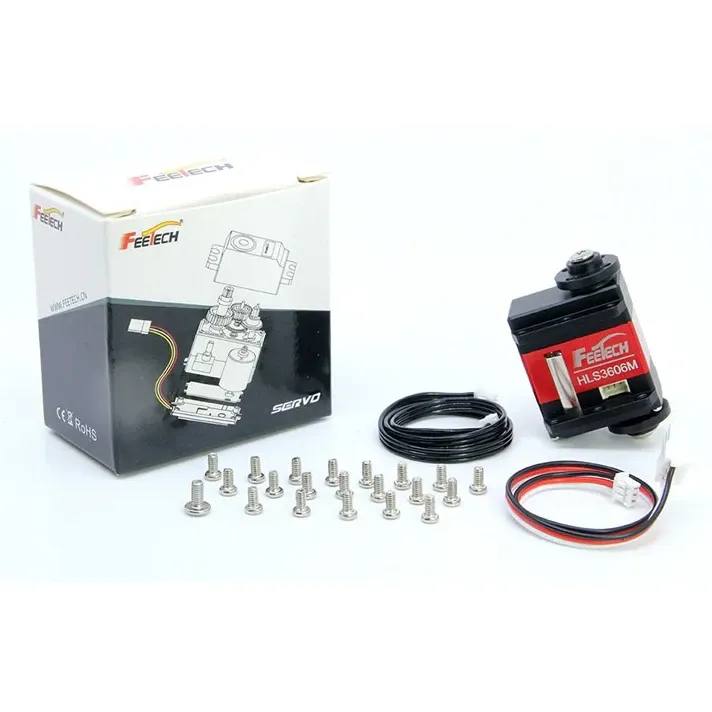
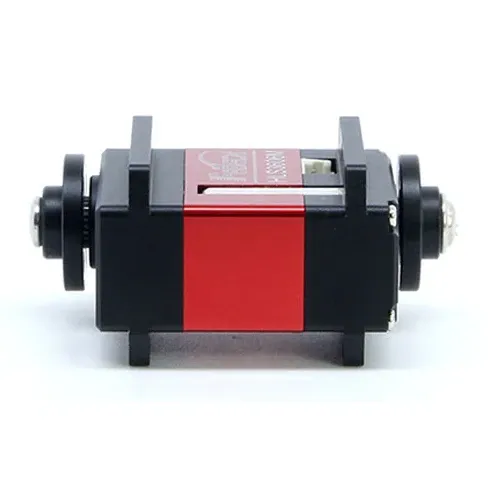
Feetech HL-3606 6V 6kg.cm 360° Metal Gear TTL Serial Bus Servo
SKU FT-HL-3606-C002
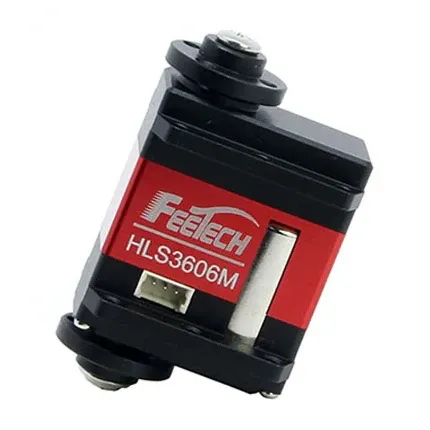
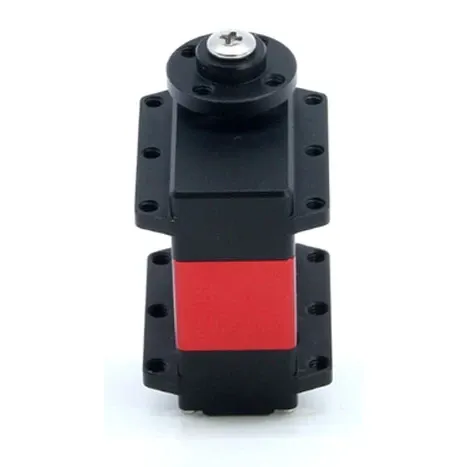
Shaft: Double Shaft (C002)
Free shipping. Pan India delivery from Gurugram, Haryana.
Ships within 3–4 business days — quality-checked in Gurugram before dispatch
Questions about this part? Ask us on WhatsApp- 100% genuine parts
- GST invoice with every order
- Secure payments — cards, UPI & net banking via Razorpay
- 7-day returns on wrong or damaged items
Product details
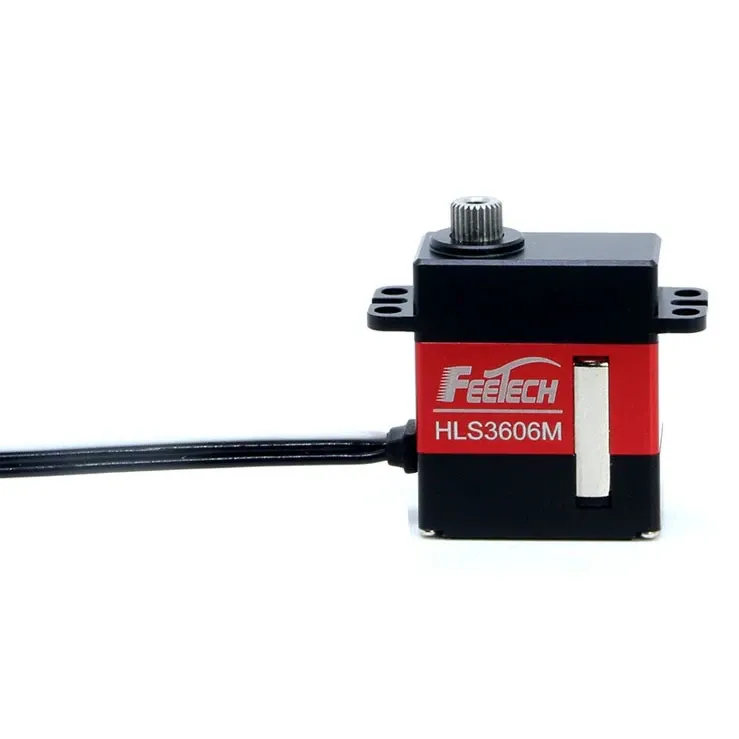
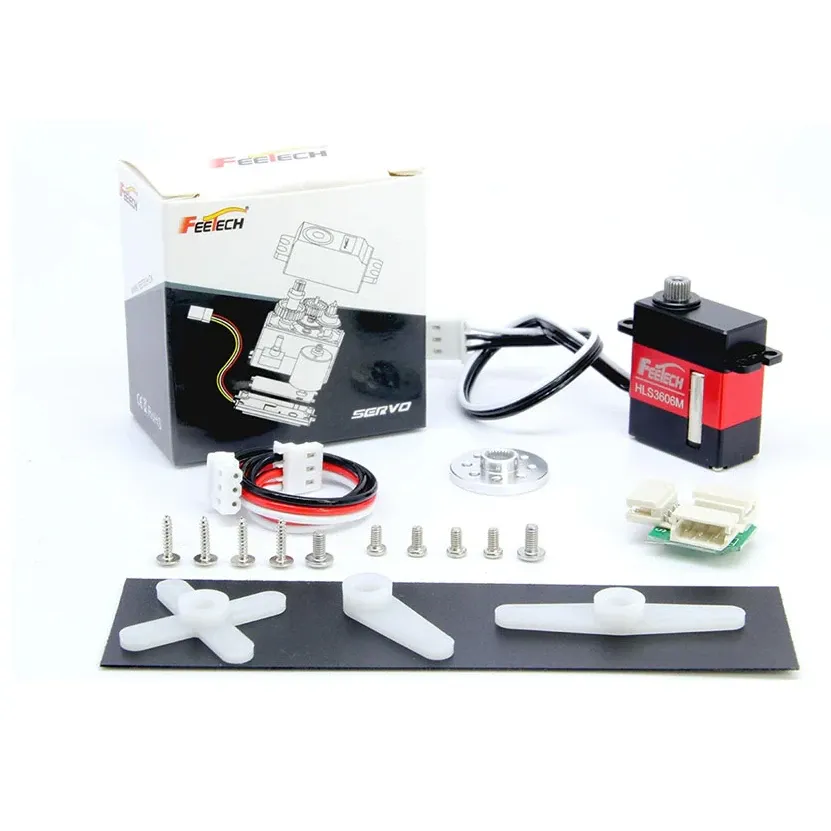
The Feetech HL-3606 is a compact TTL serial bus smart servo with an aluminium case, coreless motor and copper-and-steel gear train, producing 6kg.cm of stall torque at 6V. Multiple servos share one half-duplex serial bus, each with its own ID, which keeps wiring simple in small robot arms, pan-tilt heads, grippers and multi-joint builds.
Key features
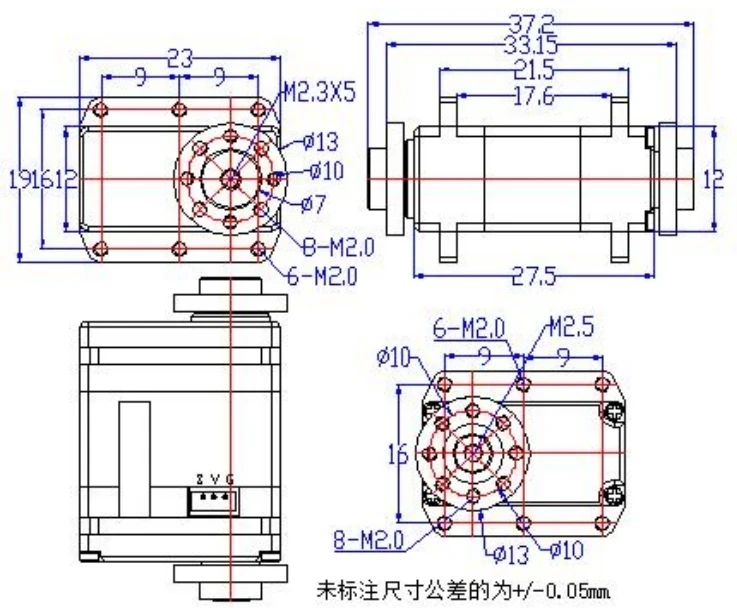
Two versions: C001 with a single output shaft, or C002 with a double shaft for supporting a bracket on both sides of a joint
360° position range with 4096-step resolution (0.088°) and PID position control
Bus IDs 0–253 at 38400bps to 1Mbps
0.09 sec/60° (111 RPM) at 6V on a 4.5–7.4V rated input
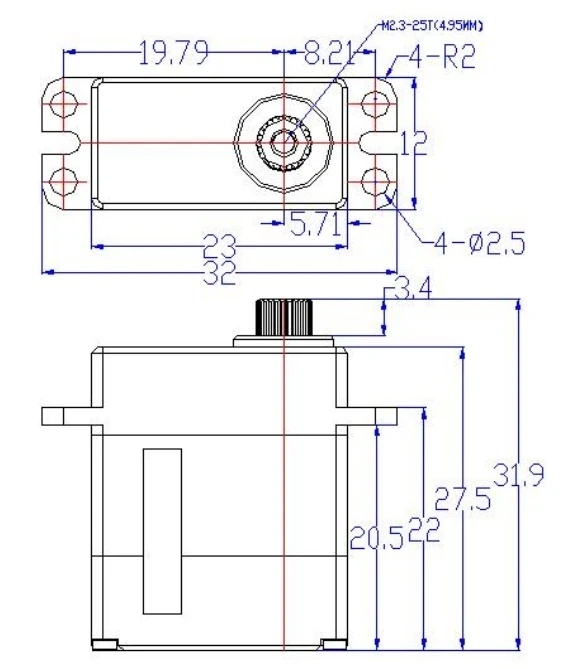
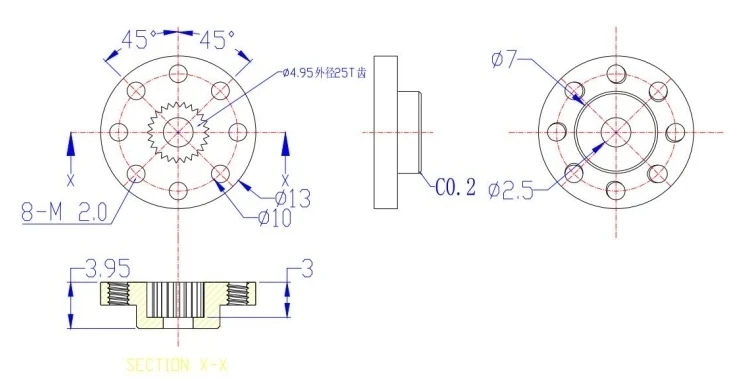
Ball bearings and a 25T output spline in a 23 x 12 x 27.5mm case
Specifications
Stall torque: 6kg.cm at 6V
Rated load: 1.5kg.cm at 6V
Speed: 0.09 sec/60° (111 RPM) at 6V
Rated input: 4.5–7.4V
Stall current: 1.3A at 6V
Rated current: 350mA at 6V
Range: 360° (0–4095), 0.088° resolution
Protocol: Half-duplex asynchronous serial (TTL)
Baud rate: 38400bps–1Mbps
ID range: 0–253
Gears: Copper + steel
Motor: Coreless
Bearings: Ball bearings
Case: Aluminium
Output spline: 25T, 4.95mm OD
Dimensions: 23 x 12 x 27.5mm
Weight: 20.6g (C001), 22.7g (C002)
Lead length: 150mm
Operating temperature: -20 to 60°C
It is commanded by digital packets rather than PWM, so drive it from a serial bus servo adapter or a microcontroller UART wired for half-duplex, not from an RC receiver or a flight controller's PWM outputs.
| Brand | Feetech |
|---|---|
| Made in India | No |
From builders
Reviews
No reviews yet — be the first to write one.
Related